Uploaded August 2014 | Updated September 2026, 5 hours ago
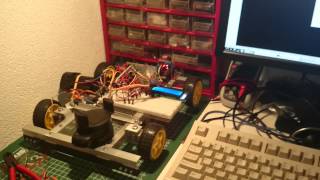
This is a homemade rc car made of aluminium and plexiglas. The dc motor is from an old dvd player and is powered by the red H-bridge board. The gearbox is made out of cheap plastic gears. It connects the Arduino Mega with a HC-05 bluetooth module to the Android phone. The app on the Android phone is Sena Bterm. The Arduino receives the keys for moving the robot around (f=forward, b=backward, l=steer left, r=steer right, etc.).

* [Arduino CNC Shield](https://blog.protoneer.co.nz/arduino-cnc-shield/)
If you want to build one yourself you can download all the necessary files on GitHub.
GitHub link:
https://github.com/leonvandenbeukel/CNC-Machine-V3
The 3D printer I use is an Anet A8. The parts are printed with PLA, mostly 20% infill and 0.2 or 0.4 setting. Use higher infill for parts that must be stronger, for example the stepper motor mounts.
Dimensions:
The tubes are 20mm x 20mm (0.78) square steel tubes. The length of the Y Axis tubes is 1000mm (40) and the length for the X Axis is approx. 820mm (32). As an alternative you could also use other dimensions than 20mm x 20mm (maybe even rounded tubes) as long as they are approximately that size. The Z axis tubes are 15mm x 15mm (0.59) aluminium square tubes, approx. 215mm long (8.5). You should measure this for yourself, check the video build. For the belts Im using GT2 6mm and pulleys.
The effective working area is 50 x 70 cm (20 x 27).
To power the NEMA 17 stepper motors Ive converted an old ATX PC power supply and used the 12V output. The type of stepper motors I use for the Y- and Z axis are: 17HS19-2004S1, the type for the X axis is: 42BYGHW811. For the wiring Ive used CAT5 network cable.
Software that I mostly use to generate and send GCode:
* bCNC (https://github.com/vlachoudis/bCNC)
* Universal Gcode Sender (https://github.com/winder/Universal-G-Code-Sender)
* Easel by Inventables (http://easel.inventables.com)
* Fusion 360 with CAM (https://www.autodesk.com/products/fusion-360/students-teachers-educators)
Contact:
Website: https://www.leonvandenbeukel.nl
GitHub: https://github.com/leonvandenbeukel 3D Printed CNC Machine V3](https://i.ytimg.com/vi/PrJPGO_sYMM/mqdefault.jpg)