Uploaded September 2026 | Updated November 2026, 11 hours ago
"From Scene to Sensor: Synthetic LiDAR for Autonomous Systems" by Michael Schwingshackl at Blender Conference 2026
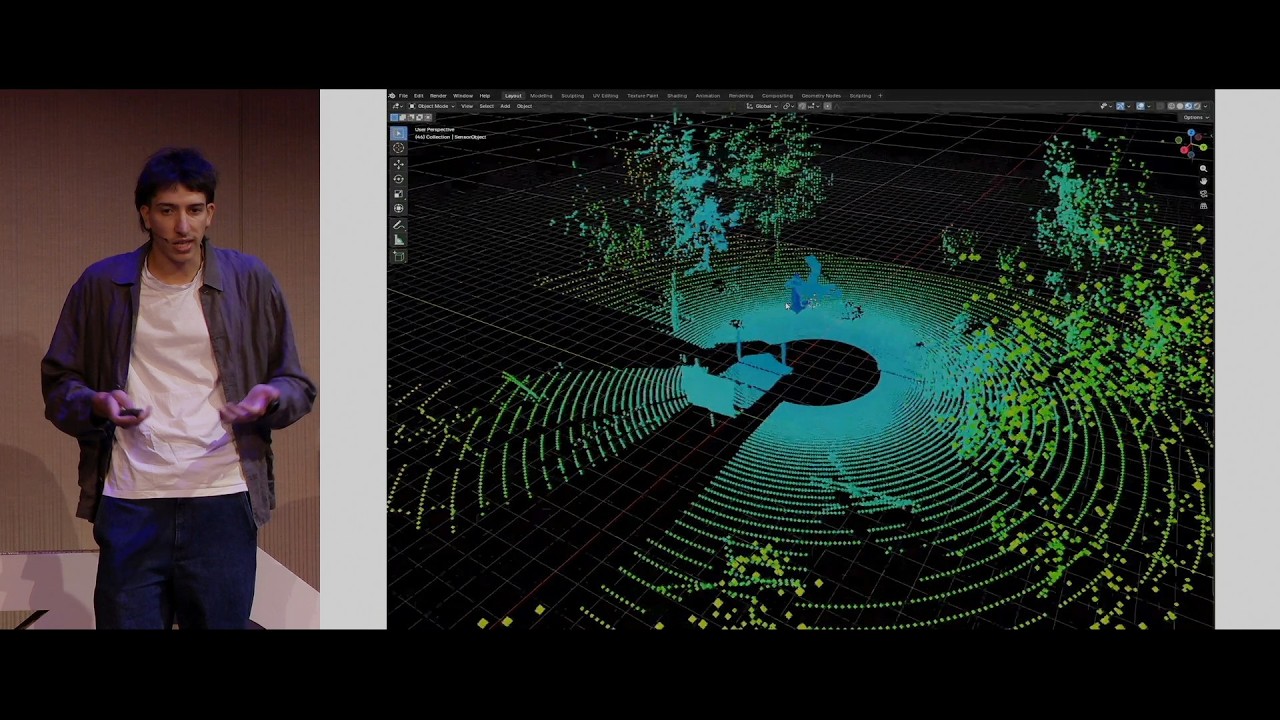
Building high-quality LiDAR datasets for autonomous systems is slow, expensive, and rarely captures the edge cases that matter most. In this talk Michael Schwingshackl shows how a procedural pipeline turns synthetic 3D environments into physically accurate LiDAR scans. He walks through Geometry Nodes as a flexible sensor simulator, capable of reproducing complex real-world scan patterns, and Python for automated data extraction, turning Blender into a high-fidelity data engine for perception research. Michael presents results from outdoor autonomous machinery in the field and discusses how perception models trained on synthetic data perform once they leave simulation, including where the sim-to-real gap still causes trouble.
–
Learn more about Blender Conference 2026 at conference.blender.org/2026
#b3d #BCON26
"From Scene to Sensor: Synthetic LiDAR for Autonomous Systems" by Michael Schwingshackl at Blender Conference 2026
Building high-quality LiDAR datasets for autonomous systems is slow, expensive, and rarely captures the edge cases that matter most. In this talk Michael Schwingshackl shows how a procedural pipeline turns synthetic 3D environments into physically accurate LiDAR scans. He walks through Geometry Nodes as a flexible sensor simulator, capable of reproducing complex real-world scan patterns, and Python for automated data extraction, turning Blender into a high-fidelity data engine for perception research. Michael presents results from outdoor autonomous machinery in the field and discusses how perception models trained on synthetic data perform once they leave simulation, including where the sim-to-real gap still causes trouble.
–
Learn more about Blender Conference 2026 at conference.blender.org/2026
#b3d #BCON26