Uploaded February 2022 | Updated September 2026, 1 hour ago
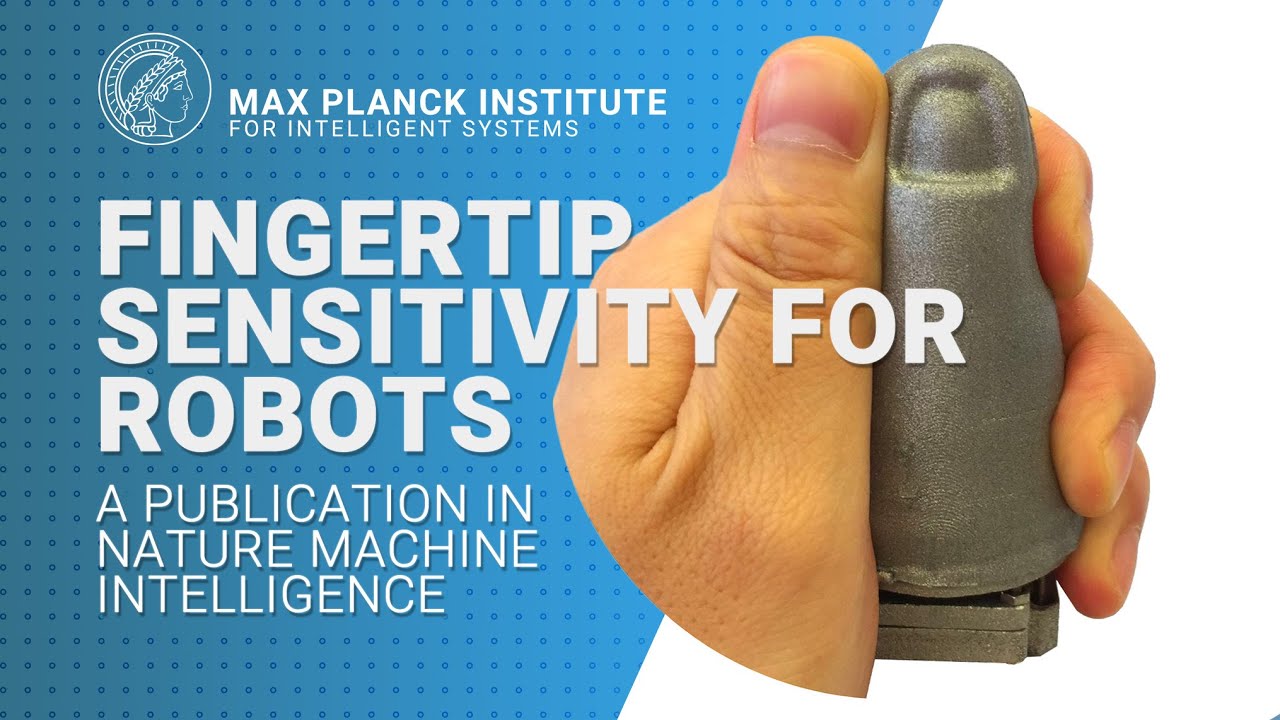
Striving to improve touch sensing in robotics, scientists at the Max Planck Institute for Intelligent Systems developed a thumb-shaped sensor with a camera hidden inside and trained a deep neural network to infer its haptic contact information. When something touches the finger, the system constructs a three-dimensional force map from the visible deformations of its flexible outer shell. This research invention significantly improves a robot finger’s haptic perception, coming ever closer to the sense of touch of human skin. On February 23, 2022, the work was published in Nature Machine Intelligence. More information can be found here: is.mpg.de/news
Striving to improve touch sensing in robotics, scientists at the Max Planck Institute for Intelligent Systems developed a thumb-shaped sensor with a camera hidden inside and trained a deep neural network to infer its haptic contact information. When something touches the finger, the system constructs a three-dimensional force map from the visible deformations of its flexible outer shell. This research invention significantly improves a robot finger’s haptic perception, coming ever closer to the sense of touch of human skin. On February 23, 2022, the work was published in Nature Machine Intelligence. More information can be found here: is.mpg.de/news