Uploaded September 2024 | Updated November 2026, 53 minutes ago
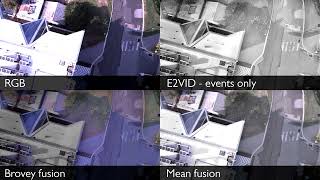
Traditionally, unmanned aerial vehicles (UAVs) rely on CMOS-based cameras to collect images about the world below. One of the most successful applications of UAVs is to generate orthomosaics or orthomaps, in which a series of images are integrated together to develop a larger map. However, the use of CMOS-based cameras with global or rolling shutters mean that orthomaps are vulnerable to challenging light conditions, motion blur, and high-speed motion of inde- pendently moving objects under the camera. Event cameras are less sensitive to these issues, as their pixels are able to trigger asynchronously on brightness changes. This work introduces the first orthomosaic approach using event cameras. In contrast to existing methods relying only on CMOS cameras, our approach enables map generation even in challenging light conditions, including direct sunlight and after sunset.
Website: evmapper.fcladera.com
Paper: arxiv.org/abs/2409.18120
Traditionally, unmanned aerial vehicles (UAVs) rely on CMOS-based cameras to collect images about the world below. One of the most successful applications of UAVs is to generate orthomosaics or orthomaps, in which a series of images are integrated together to develop a larger map. However, the use of CMOS-based cameras with global or rolling shutters mean that orthomaps are vulnerable to challenging light conditions, motion blur, and high-speed motion of inde- pendently moving objects under the camera. Event cameras are less sensitive to these issues, as their pixels are able to trigger asynchronously on brightness changes. This work introduces the first orthomosaic approach using event cameras. In contrast to existing methods relying only on CMOS cameras, our approach enables map generation even in challenging light conditions, including direct sunlight and after sunset.
Website: evmapper.fcladera.com
Paper: arxiv.org/abs/2409.18120