Uploaded December 2017 | Updated September 2026, 2 hours ago
Implementing a simple trajectory tracking algorithm for your drone through Mavlink commands using Python.
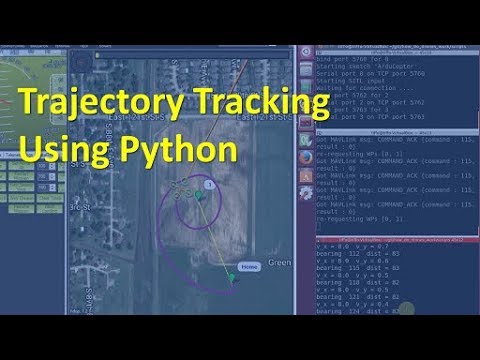
We provide a waypoint with Mission Planner and our script creates a circular path around it. Our tracking algorithm sets the lateral velocity proportional to the off track error and keeps the heading tangent to the path.
We apply the algorithm to a simple circular trajectory. For a fixed wing implementation, check out this nice paper of Park et. al. (in the video I put Parks' name... sorry)
pdfs.semanticscholar.org/c9bd/e4cac35afc70379a02adc1d977ec1aadd07f.pdf
Check out my previous tutorials, especially this one about Drone Delivery: youtu.be/iL5DIqL9qdE
Find the code on my Github: github.com/tizianofiorenzani/how_do_drones_work
Implementing a simple trajectory tracking algorithm for your drone through Mavlink commands using Python.
We provide a waypoint with Mission Planner and our script creates a circular path around it. Our tracking algorithm sets the lateral velocity proportional to the off track error and keeps the heading tangent to the path.
We apply the algorithm to a simple circular trajectory. For a fixed wing implementation, check out this nice paper of Park et. al. (in the video I put Parks' name... sorry)
pdfs.semanticscholar.org/c9bd/e4cac35afc70379a02adc1d977ec1aadd07f.pdf
Check out my previous tutorials, especially this one about Drone Delivery: youtu.be/iL5DIqL9qdE
Find the code on my Github: github.com/tizianofiorenzani/how_do_drones_work


