Uploaded November 2026 | Updated November 2026, 3 hours ago
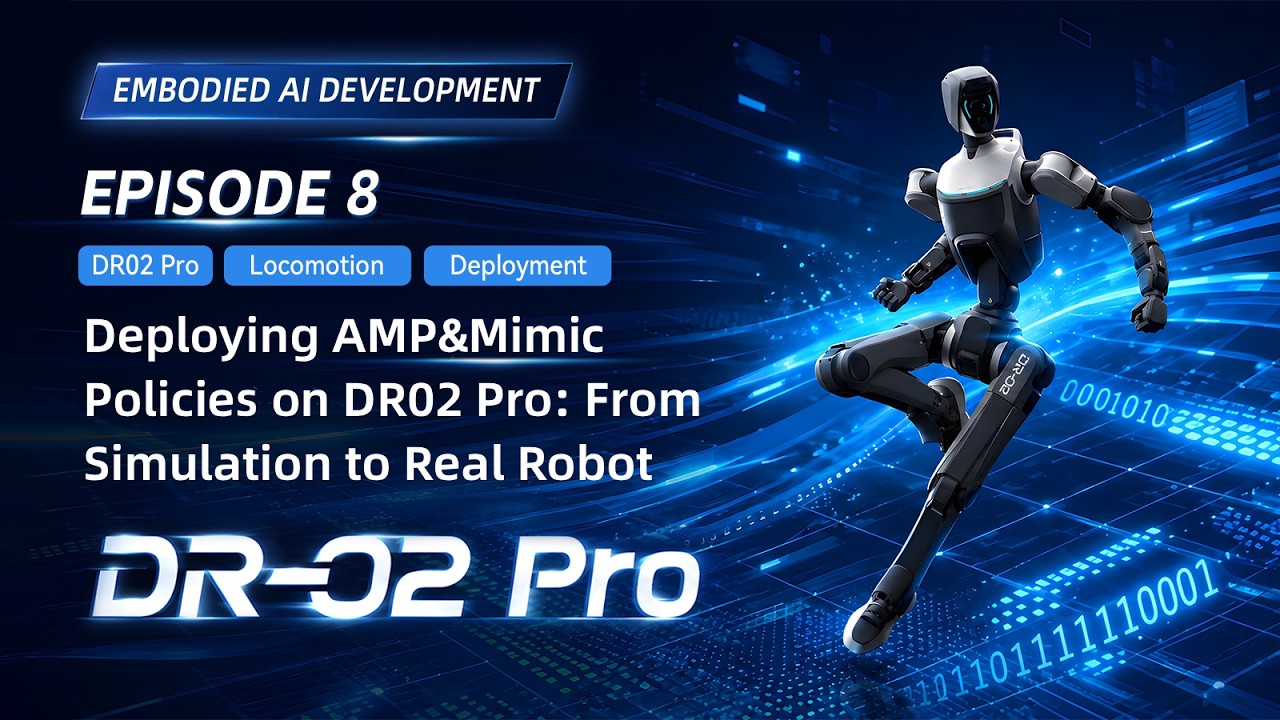
This video provides a detailed guide to deploying trained AMP and Mimic motion control policies on the DR02 Pro humanoid robot using deep-robotics-sdk2.
In this video, we will cover:
1. An overview of the deep-robotics-sdk2 project structure.
2. Building the simulation deployment environment, deploying AMP and Mimic policies, and switching the robot's control modes using the keyboard.
3. Building the real-robot deployment environment, deploying the policies, and controlling the robot with a gamepad.
4. Important safety precautions during real-robot deployment.
We encourage you to follow the tutorial and try deploying and validating your own trained motion control policies.
You can find the related projects and detailed documentation at the links below:
1. deep-robotics-sdk2: github.com/DeepRoboticsLab/deep-robotics-sdk2
2. deep-robotics-msgs: github.com/DeepRoboticsLab/deep-robotics-msgs
3. deep-robotics-simulation: github.com/DeepRoboticsLab/deep-robotics-simulation
This video provides a detailed guide to deploying trained AMP and Mimic motion control policies on the DR02 Pro humanoid robot using deep-robotics-sdk2.
In this video, we will cover:
1. An overview of the deep-robotics-sdk2 project structure.
2. Building the simulation deployment environment, deploying AMP and Mimic policies, and switching the robot's control modes using the keyboard.
3. Building the real-robot deployment environment, deploying the policies, and controlling the robot with a gamepad.
4. Important safety precautions during real-robot deployment.
We encourage you to follow the tutorial and try deploying and validating your own trained motion control policies.
You can find the related projects and detailed documentation at the links below:
1. deep-robotics-sdk2: github.com/DeepRoboticsLab/deep-robotics-sdk2
2. deep-robotics-msgs: github.com/DeepRoboticsLab/deep-robotics-msgs
3. deep-robotics-simulation: github.com/DeepRoboticsLab/deep-robotics-simulation