Uploaded April 2019 | Updated September 2026, 2 hours ago
** Visit my brand new portal at tiziano-school.thinkific.com where you can find this ROS series as a FREE course **
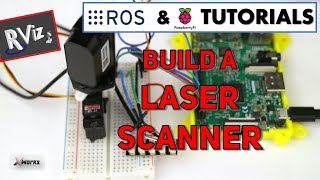
A Laser Scanner can be obtained by rotating a lidar, using a motor and encoder or a stepper motor. In this example we'll be using a simple RC servo. Once we have the scan information, it can be integrated in ROS using a LaserScan message and then visualized in Rviz
In this example we build a cheap laser scanner using a TfMini plus lidar, a servo and a Raspberry Pi. We develop a library for controlling the servo and one for reading the laser. Then we create a servo scanner library and a ROS node. Finally we visualize the scan in Rviz
__________________________________________________________
NOTE [June 2019]: The TfMini Plus now works with UART and I2C
en.benewake.com/res/wuliu/docs/15614876323609996SJ-GU-TFmini%20Plus-01-A04-Datasheet.pdf
__________________________________________________________
We will use Servoblaster for controlling the servo directly from the Raspberry Pi
*** Thanks to Benewake for supplying the TfMini plus lidar: en.benewake.com ***
MAIN VIDEO:
1:32 - How it works
3:00 - TfMini library
3:40 - Servoblaster
5:40 - Servo Scanner Library
7:03 - ROS Node
9:47 - Rviz
*** PARTS ***
Benewake TfMini Lidar: amzn.to/2UvDBuS
Benewake TfMini Plus Lidar: amzn.to/2DpV3eo
Raspberry Pi 3 B (amzn.to/2GvqUuN) or B+ (amzn.to/2Xzqf2o)
- Raspberry Pi 4 (4 GB RAM): amzn.to/36GqwXf
- Raspberry Pi 4 (2 GB RAM): amzn.to/2Aj7Pg3
- Wide angle camera: amzn.to/2Pwc6P7
3D printed laser bracket: github.com/tizianofiorenzani/ros_tutorials/tree/master/laser_scanner_tfmini/3dprint
i2c Splitter (Pixhawk style): amzn.to/2WxMPIS
*** FIND THE CODE:
* My Github: github.com/tizianofiorenzani/ros_tutorials
TfMini Github: github.com/TFmini/TFmini-RaspberryPi
ServoBlaster Github: github.com/richardghirst/PiBits/tree/master/ServoBlaster
*** WATCH THE WHOLE ROS TUTORIAL SERIES: youtube.com/playlist?list=PLuteWQUGtU9BU0sQIVqRQa24p-pSBCYNv
** DRONE TUTORIAL SERIES: youtube.com/watch?v=TFDWs_DG2QY&list=PLuteWQUGtU9BcXXr3jCG00uVXFwQJkLRa
*** Connect the TfMini to Ardupilot/Arducopter: ardupilot.org/copter/docs/common-benewake-tfmini-lidar.html
******** Find me on Facebook
facebook.com/tizianotutorials
******** Find me on Linkedin
linkedin.com/in/tiziano-fiorenzani
******** Find me on Twitter
twitter.com/TFiorenzani
** Go to my channel: goo.gl/BjLGnS
** Check out my latest video: goo.gl/ZhcNi4
** Check out my most popular video: goo.gl/5KMJnU
#ros #tutorial #laserscanner #lidar
** Visit my brand new portal at tiziano-school.thinkific.com where you can find this ROS series as a FREE course **
A Laser Scanner can be obtained by rotating a lidar, using a motor and encoder or a stepper motor. In this example we'll be using a simple RC servo. Once we have the scan information, it can be integrated in ROS using a LaserScan message and then visualized in Rviz
In this example we build a cheap laser scanner using a TfMini plus lidar, a servo and a Raspberry Pi. We develop a library for controlling the servo and one for reading the laser. Then we create a servo scanner library and a ROS node. Finally we visualize the scan in Rviz
__________________________________________________________
NOTE [June 2019]: The TfMini Plus now works with UART and I2C
en.benewake.com/res/wuliu/docs/15614876323609996SJ-GU-TFmini%20Plus-01-A04-Datasheet.pdf
__________________________________________________________
We will use Servoblaster for controlling the servo directly from the Raspberry Pi
*** Thanks to Benewake for supplying the TfMini plus lidar: en.benewake.com ***
MAIN VIDEO:
1:32 - How it works
3:00 - TfMini library
3:40 - Servoblaster
5:40 - Servo Scanner Library
7:03 - ROS Node
9:47 - Rviz
*** PARTS ***
Benewake TfMini Lidar: amzn.to/2UvDBuS
Benewake TfMini Plus Lidar: amzn.to/2DpV3eo
Raspberry Pi 3 B (amzn.to/2GvqUuN) or B+ (amzn.to/2Xzqf2o)
- Raspberry Pi 4 (4 GB RAM): amzn.to/36GqwXf
- Raspberry Pi 4 (2 GB RAM): amzn.to/2Aj7Pg3
- Wide angle camera: amzn.to/2Pwc6P7
3D printed laser bracket: github.com/tizianofiorenzani/ros_tutorials/tree/master/laser_scanner_tfmini/3dprint
i2c Splitter (Pixhawk style): amzn.to/2WxMPIS
*** FIND THE CODE:
* My Github: github.com/tizianofiorenzani/ros_tutorials
TfMini Github: github.com/TFmini/TFmini-RaspberryPi
ServoBlaster Github: github.com/richardghirst/PiBits/tree/master/ServoBlaster
*** WATCH THE WHOLE ROS TUTORIAL SERIES: youtube.com/playlist?list=PLuteWQUGtU9BU0sQIVqRQa24p-pSBCYNv
** DRONE TUTORIAL SERIES: youtube.com/watch?v=TFDWs_DG2QY&list=PLuteWQUGtU9BcXXr3jCG00uVXFwQJkLRa
*** Connect the TfMini to Ardupilot/Arducopter: ardupilot.org/copter/docs/common-benewake-tfmini-lidar.html
******** Find me on Facebook
facebook.com/tizianotutorials
******** Find me on Linkedin
linkedin.com/in/tiziano-fiorenzani
******** Find me on Twitter
twitter.com/TFiorenzani
** Go to my channel: goo.gl/BjLGnS
** Check out my latest video: goo.gl/ZhcNi4
** Check out my most popular video: goo.gl/5KMJnU
#ros #tutorial #laserscanner #lidar