Uploaded October 2019 | Updated November 2026, 6 days ago
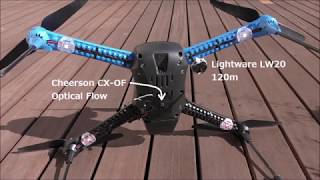
This is a test of ArduPilot Copter-3.7.0-'s "Bendy Ruler" object avoidance using a forward facing Lidar (a Lightware LW20). Objects detected appear as green airplanes because we are temporarily using the "ADSB" message to send the info to the ground station.
Special thanks to Tom Pittenger who wrote the "Object Database" that allows this to work.
Note: I hesitated to publish this video because it is generally not a good idea to stand in the path of a moving drone so please don't try this at home. It's much smarter to create static barriers using benches, trees, etc.
wiki: ardupilot.org/copter/docs/common-oa-bendyruler.html
This is a test of ArduPilot Copter-3.7.0-'s "Bendy Ruler" object avoidance using a forward facing Lidar (a Lightware LW20). Objects detected appear as green airplanes because we are temporarily using the "ADSB" message to send the info to the ground station.
Special thanks to Tom Pittenger who wrote the "Object Database" that allows this to work.
Note: I hesitated to publish this video because it is generally not a good idea to stand in the path of a moving drone so please don't try this at home. It's much smarter to create static barriers using benches, trees, etc.
wiki: ardupilot.org/copter/docs/common-oa-bendyruler.html