Uploaded April 2025 | Updated November 2026, 5 days ago
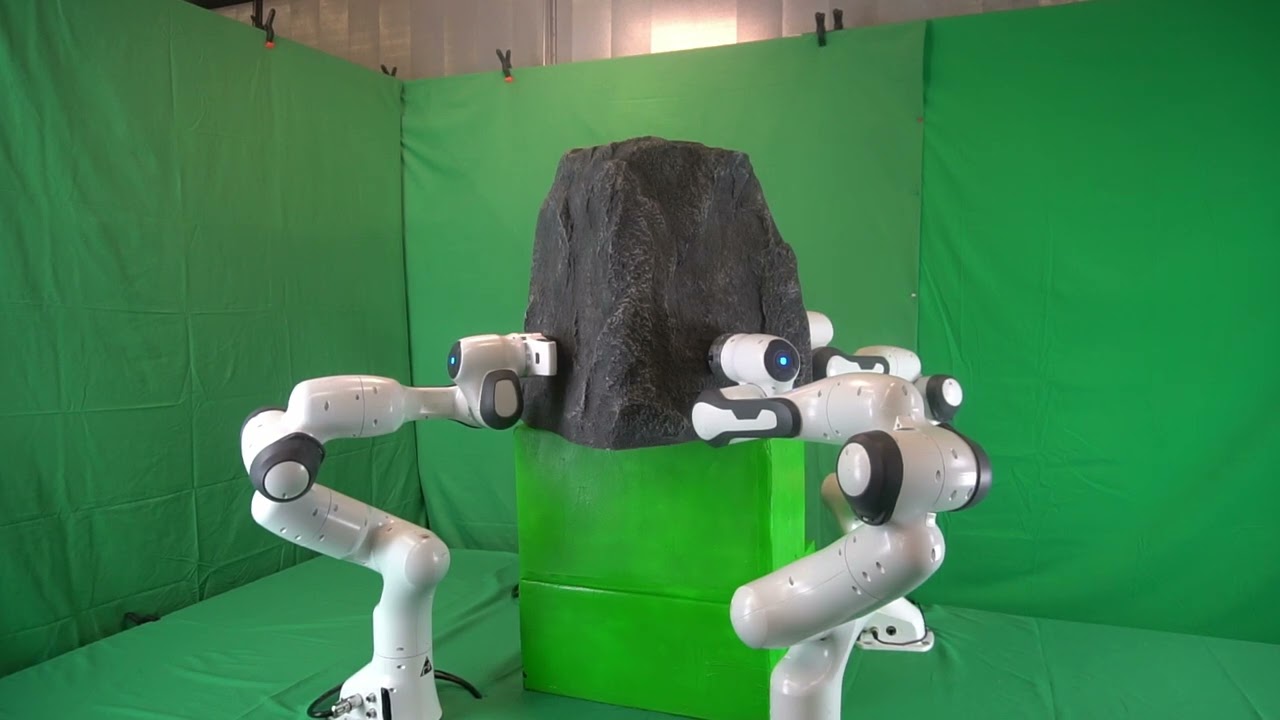
The robots push 35 Newton force to the stone to hold it firmly so it can lift and carry it. However, using only two robots, each 35 N, is not enough for such a heavy and gigantic object. As the controller is modular, we can add/remove more robots on the go. So, two extra robots are added so that with 4, we can now do what we wanted to do.
More information about the work of Erfan Shahriari, who shortly won the Georg Girald PhD Award: mirmi.tum.de/en/mirmi/news/article/mirmi-student-erfan-shariari-gewinnt-den-georg-giralt-phd-award
This research is part of his work at the Munich Institute of Robotikcs and Machine Intelligence (MIRMI) at the Technical University of Munich (TUM).
The robots push 35 Newton force to the stone to hold it firmly so it can lift and carry it. However, using only two robots, each 35 N, is not enough for such a heavy and gigantic object. As the controller is modular, we can add/remove more robots on the go. So, two extra robots are added so that with 4, we can now do what we wanted to do.
More information about the work of Erfan Shahriari, who shortly won the Georg Girald PhD Award: mirmi.tum.de/en/mirmi/news/article/mirmi-student-erfan-shariari-gewinnt-den-georg-giralt-phd-award
This research is part of his work at the Munich Institute of Robotikcs and Machine Intelligence (MIRMI) at the Technical University of Munich (TUM).