Uploaded June 2024 | Updated November 2026, 12 hours ago
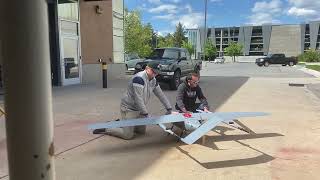
This video shows a quadplane running ArduPilot in MANUAL mode. The forward throttle is raised with no other stick input. The ailerons deflect when the throttle gets to 90% due to corruption of the PWM signal due to the cables being run close to the fwd ESC power wires
The fix was to use 5v signalling on the PWM cables. This can be done either with external level shifter adapters or with the CubeOrange on the 8 main outputs by setting BRD_PWM_VOLT_SEL=1
With thanks to AggieAir from Utah State University for the video
This video shows a quadplane running ArduPilot in MANUAL mode. The forward throttle is raised with no other stick input. The ailerons deflect when the throttle gets to 90% due to corruption of the PWM signal due to the cables being run close to the fwd ESC power wires
The fix was to use 5v signalling on the PWM cables. This can be done either with external level shifter adapters or with the CubeOrange on the 8 main outputs by setting BRD_PWM_VOLT_SEL=1
With thanks to AggieAir from Utah State University for the video