Uploaded July 2024 | Updated November 2026, 48 minutes ago
Link:
tinyurl.com/intent-capability
Abstract:
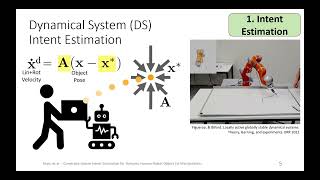
Constraint-aware estimation of human intent is essential for robots to physically collaborate and interact with humans. Further, to achieve fluid collaboration in dynamic tasks intent estimation should be achieved in real-time. In this paper, we present a framework that combines online estimation and control to facilitate robots in interpreting human intentions, and dynamically adjust their actions to assist in dynamic object co-manipulation tasks while considering both robot and human constraints. Central to our approach is the adoption of a Dynamic Systems (DS) model to represent human intent. Such a low-dimensional parameterized model, along with human manipulability and robot kinematic constraints, enables us to predict intent using a particle filter solely based on past motion data and tracking errors. For safe assistive control, we propose a variable impedance controller that adapts the robot's impedance to offer assistance based on the intent estimation confidence from the DS particle filter. We validate our framework on a challenging real-world human-robot co-manipulation task and present promising results over baselines. Our framework represents a significant step forward in physical human-robot collaboration (pHRC), ensuring that robot cooperative interactions with humans are both feasible and effective.
Link:
tinyurl.com/intent-capability
Abstract:
Constraint-aware estimation of human intent is essential for robots to physically collaborate and interact with humans. Further, to achieve fluid collaboration in dynamic tasks intent estimation should be achieved in real-time. In this paper, we present a framework that combines online estimation and control to facilitate robots in interpreting human intentions, and dynamically adjust their actions to assist in dynamic object co-manipulation tasks while considering both robot and human constraints. Central to our approach is the adoption of a Dynamic Systems (DS) model to represent human intent. Such a low-dimensional parameterized model, along with human manipulability and robot kinematic constraints, enables us to predict intent using a particle filter solely based on past motion data and tracking errors. For safe assistive control, we propose a variable impedance controller that adapts the robot's impedance to offer assistance based on the intent estimation confidence from the DS particle filter. We validate our framework on a challenging real-world human-robot co-manipulation task and present promising results over baselines. Our framework represents a significant step forward in physical human-robot collaboration (pHRC), ensuring that robot cooperative interactions with humans are both feasible and effective.