Uploaded September 2017 | Updated September 2026, 1 week ago
demonstrations.wolfram.com/CommonRobotArmConfigurations
The Wolfram Demonstrations Project contains thousands of free interactive visualizations, with new entries added daily.
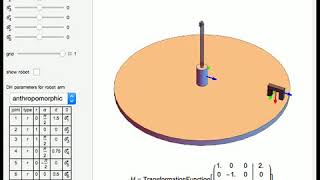
Robot manipulators can be concisely described by a convention called the Denavit-Hartenberg parameters (DH parameters) to assign one variable and three parameters to describe the distance and angular offset between each joint. This Demonstration a...
Contributed by: Mohammad Sultan and Aaron T. Becker
Audio created with WolframTones:
tones.wolfram.com
demonstrations.wolfram.com/CommonRobotArmConfigurations
The Wolfram Demonstrations Project contains thousands of free interactive visualizations, with new entries added daily.
Robot manipulators can be concisely described by a convention called the Denavit-Hartenberg parameters (DH parameters) to assign one variable and three parameters to describe the distance and angular offset between each joint. This Demonstration a...
Contributed by: Mohammad Sultan and Aaron T. Becker
Audio created with WolframTones:
tones.wolfram.com