Uploaded July 2018 | Updated September 2026, 1 day ago
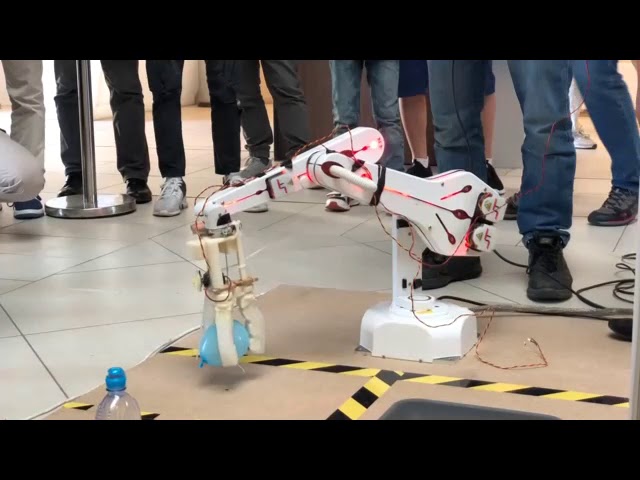
Cambridge engineering PhD students took first place in the manipulation division of the RoboSoft 2018 Competition with their robot CambridgeArm. There were three tasks: moving a soft manipulator through obstacles to touch a remote point; picking up a number of challenging objects such as a balloon (as this video shows); and opening a door handle. The tasks were performed autonomously with a robotic manipulation platform which the students developed and programmed themselves:
Cambridge engineering PhD students took first place in the manipulation division of the RoboSoft 2018 Competition with their robot CambridgeArm. There were three tasks: moving a soft manipulator through obstacles to touch a remote point; picking up a number of challenging objects such as a balloon (as this video shows); and opening a door handle. The tasks were performed autonomously with a robotic manipulation platform which the students developed and programmed themselves: