Uploaded March 2012 | Updated September 2026, 2 weeks ago
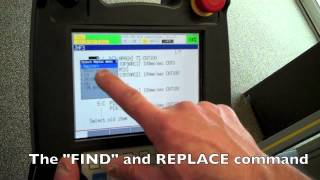
Each student developed 3 programs. One for each number. Programs were tested and run individually. The assignment required them to combine all three programs into one, using the CALL instruction and to optimize program flow. Students accomplished this by eliminating individual home positions in each program and replacing them with a global position [PR] in the CALL program. They also improved efficiency (run time) by replacing all "SPEED" motion elements to the allowed maximum of 250mm/sec.
Students developed the script, narration and video in a small group setting.
All training is offered for FREE on state of the art equipment and software through a federal grant by the Economic Development Administration (EDA) in the cities of Portage, Reedsburg and Waterloo.
Students are enrolled in "Robotics for Industrial Automation - level 1" funded through the EDA.
Each student developed 3 programs. One for each number. Programs were tested and run individually. The assignment required them to combine all three programs into one, using the CALL instruction and to optimize program flow. Students accomplished this by eliminating individual home positions in each program and replacing them with a global position [PR] in the CALL program. They also improved efficiency (run time) by replacing all "SPEED" motion elements to the allowed maximum of 250mm/sec.
Students developed the script, narration and video in a small group setting.
All training is offered for FREE on state of the art equipment and software through a federal grant by the Economic Development Administration (EDA) in the cities of Portage, Reedsburg and Waterloo.
Students are enrolled in "Robotics for Industrial Automation - level 1" funded through the EDA.