Uploaded March 2026 | Updated September 2026, 2 days ago
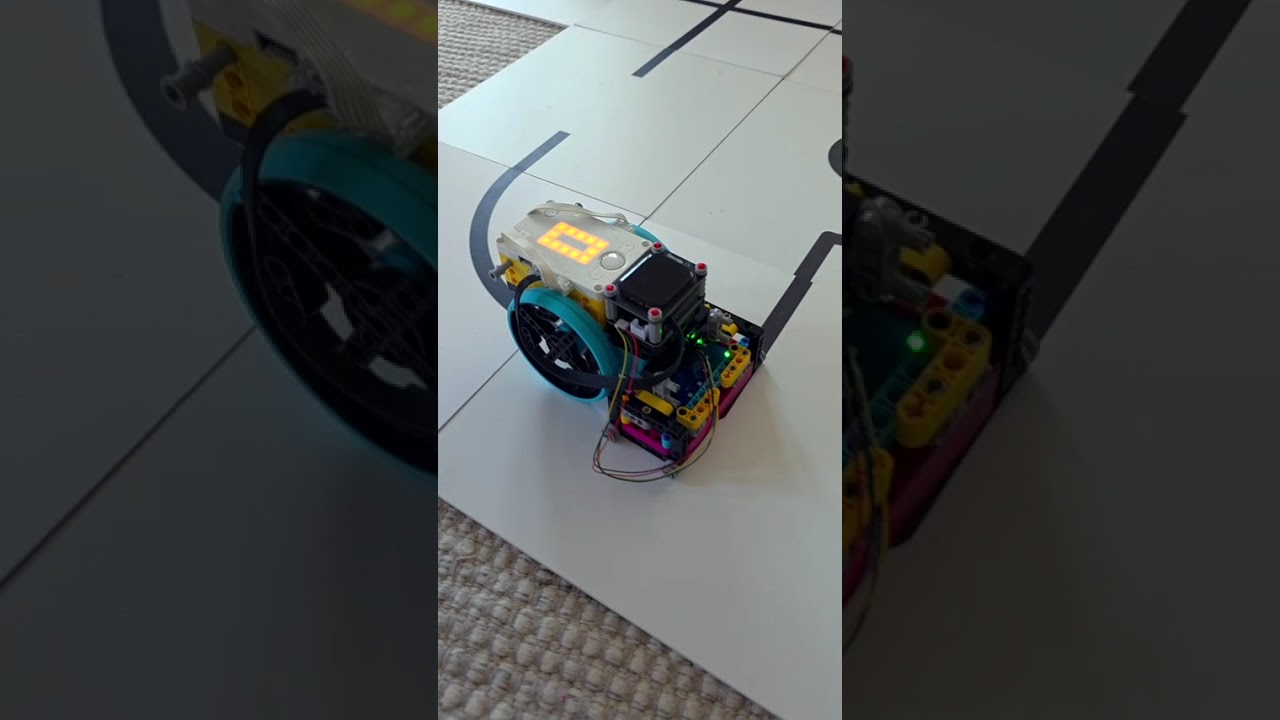
I built a hard track with all #robocup tiles I have. This demo shows the calibration functionality of the line sensor. You pass it over the line a few times and then it stores values in EEPROM for next time. This helps you adjust for different tiles and different lighting conditions at competitions.
I built a hard track with all #robocup tiles I have. This demo shows the calibration functionality of the line sensor. You pass it over the line a few times and then it stores values in EEPROM for next time. This helps you adjust for different tiles and different lighting conditions at competitions.