Uploaded March 2023 | Updated November 2026, 1 hour ago
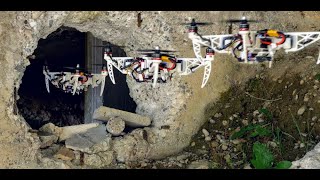
Agilicious is a co-designed hardware and software framework tailored to autonomous, agile quadrotor flight, which has been developed and used since 2016 at the Robotics and Perception Group of the University of Zurich. Agilicious is described in our Science Robotics 2022 paper, linked below. It is completely open-source and open hardware and supports both model-based and neural-network-based controllers! Also, it provides high thrust-to-weight and torque-to-inertia ratios for agility, onboard vision sensors, GPU-accelerated compute hardware for real-time perception and neural-network inference, a real-time flight controller, and a versatile software stack. In contrast to existing frameworks, Agilicious offers a unique combination of flexible software and high-performance hardware. Agilicious has been used in over 30 scientific papers at our lab, including trajectory tracking for drone racing scenarios at up to 5g and 70km/h [SciRob21_Foehn], vision-based acrobatic flight [RSS20_Kaufmann), obstacle avoidance in both structured and unstructured environments using solely onboard perception [SciRob21_Loquercio], and hardware-in-the-loop simulation in virtual-reality environments! Thanks to its versatility, we believe that Agilicious supports the next generation of scientific and industrial quadrotor research. Agilicious allows you to seamlessly develop, test, reproduce, and benchmark control algorithms such as Non-linear Model Predictive Control (MPC), differential-flatness-based control (DFBC), and INDI (Incremental Non-linear Dynamic Inversion) [TRO 2022_Sun]. Agilicious also includes our state-of-the-art, high-fidelity simulator, which uses Blade Element Momentum (BEM) theory for the propeller model and provides accurate estimates of the quadcopter’s aerodynamic characteristics across the flight envelope [RSS 2021_Bauersfeld].
Agilicious webpage: https://agilicious.dev/
References:
Agilicious' main reference (all open-access PDFs and videos can be found on the Agilicious page):
Foehn, Kaufmann, Romero, Penicka, Sun, Bauersfeld, Laengle, Cioffi, Song, Loquercio, Scaramuzza, “Agilicious: Open-Source and Open-Hardware Agile Quadrotor for Vision-Based Flight”, AAAS Science Robotics, 2022.
PDF: https://rpg.ifi.uzh.ch/docs/ScienceRobotics22_Foehn.pdf
Agilicious implements the algorithms described in the following papers:
[SciRob21_Foehn] Philipp Foehn, Angel Romero, Davide Scaramuzza, “Time-Optimal Planning for Quadrotor Waypoint Flight”, Science Robotics, 2021,
PDF: https://rpg.ifi.uzh.ch/docs/ScienceRobotics21_Foehn.pdf
[RSS20_Kaufmann] Elia Kaufmann, Antonio Loquercio, Rene Ranftl, Mark Müller, Vladlen Koltun, Davide Scaramuzza, “Deep Drone Acrobatics”, RSS: Robotics, Science, and Systems, 2020,
PDF: https://rpg.ifi.uzh.ch/docs/RSS20_Kaufmann.pdf
[SciRob21_Loquercio] Antonio Loquercio, Elia Kaufmann, Rene Ranftl, Mark Müller, Vladlen Koltun, Davide Scaramuzza, “Learning High-Speed Flight in the Wild”, Science Robotics, 2021,
PDF: https://rpg.ifi.uzh.ch/docs/Loquercio21_Science.pdf
[TRO 2022_Sun] Sihao Sun, Angel Romero, Philipp Foehn, Elia Kaufmann, Davide Scaramuzza, “A Comparative Study of Nonlinear MPC and Differential-Flatness-based Control for Quadrotor Agile Flight”, IEEE Transactions on Robotics, 2022,
PDF: https://rpg.ifi.uzh.ch/docs/Arxiv21_MPC_Sun.pdf
[RSS 2021_Bauersfeld] Leonard Bauersfeld, Elia Kaufmann, Philipp Foehn, Sihao Sun, Davide Scaramuzza, “NeuroBEM: Hybrid Aerodynamic Quadrotor Model”, RSS: Robotics, Science, and Systems, 2021,
PDF: https://rpg.ifi.uzh.ch/docs/RSS21_Bauersfeld.pdf
Matthias Faessler, Antonio Franchi, Davide Scaramuzza, “Differential Flatness of Quadrotor Dynamics Subject to Rotor Drag for Accurate Tracking of High-Speed Trajectories”, IEEE Robotics and Automation Letters, 2018.
PDF: https://rpg.ifi.uzh.ch/docs/RAL18_Faessler.pdf
Our research in Agile Drone Flight:
http://rpg.ifi.uzh.ch/aggressive_flight.html
Affiliations:
P. Foehn, E. Kaufmann, A. Romero, R. Penicka, S. Sun, L. Bauersfeld, T. Laengle, Y. Song, A. Loquercio, D. Scaramuzza are with the Robotics and Perception Group, University of Zurich, Switzerland
http://rpg.ifi.uzh.ch/
Music Credits: scottholmesmusic.com under Free Creative Commons License
Agilicious is a co-designed hardware and software framework tailored to autonomous, agile quadrotor flight, which has been developed and used since 2016 at the Robotics and Perception Group of the University of Zurich. Agilicious is described in our Science Robotics 2022 paper, linked below. It is completely open-source and open hardware and supports both model-based and neural-network-based controllers! Also, it provides high thrust-to-weight and torque-to-inertia ratios for agility, onboard vision sensors, GPU-accelerated compute hardware for real-time perception and neural-network inference, a real-time flight controller, and a versatile software stack. In contrast to existing frameworks, Agilicious offers a unique combination of flexible software and high-performance hardware. Agilicious has been used in over 30 scientific papers at our lab, including trajectory tracking for drone racing scenarios at up to 5g and 70km/h [SciRob21_Foehn], vision-based acrobatic flight [RSS20_Kaufmann), obstacle avoidance in both structured and unstructured environments using solely onboard perception [SciRob21_Loquercio], and hardware-in-the-loop simulation in virtual-reality environments! Thanks to its versatility, we believe that Agilicious supports the next generation of scientific and industrial quadrotor research. Agilicious allows you to seamlessly develop, test, reproduce, and benchmark control algorithms such as Non-linear Model Predictive Control (MPC), differential-flatness-based control (DFBC), and INDI (Incremental Non-linear Dynamic Inversion) [TRO 2022_Sun]. Agilicious also includes our state-of-the-art, high-fidelity simulator, which uses Blade Element Momentum (BEM) theory for the propeller model and provides accurate estimates of the quadcopter’s aerodynamic characteristics across the flight envelope [RSS 2021_Bauersfeld].
Agilicious webpage: https://agilicious.dev/
References:
Agilicious' main reference (all open-access PDFs and videos can be found on the Agilicious page):
Foehn, Kaufmann, Romero, Penicka, Sun, Bauersfeld, Laengle, Cioffi, Song, Loquercio, Scaramuzza, “Agilicious: Open-Source and Open-Hardware Agile Quadrotor for Vision-Based Flight”, AAAS Science Robotics, 2022.
PDF: https://rpg.ifi.uzh.ch/docs/ScienceRobotics22_Foehn.pdf
Agilicious implements the algorithms described in the following papers:
[SciRob21_Foehn] Philipp Foehn, Angel Romero, Davide Scaramuzza, “Time-Optimal Planning for Quadrotor Waypoint Flight”, Science Robotics, 2021,
PDF: https://rpg.ifi.uzh.ch/docs/ScienceRobotics21_Foehn.pdf
[RSS20_Kaufmann] Elia Kaufmann, Antonio Loquercio, Rene Ranftl, Mark Müller, Vladlen Koltun, Davide Scaramuzza, “Deep Drone Acrobatics”, RSS: Robotics, Science, and Systems, 2020,
PDF: https://rpg.ifi.uzh.ch/docs/RSS20_Kaufmann.pdf
[SciRob21_Loquercio] Antonio Loquercio, Elia Kaufmann, Rene Ranftl, Mark Müller, Vladlen Koltun, Davide Scaramuzza, “Learning High-Speed Flight in the Wild”, Science Robotics, 2021,
PDF: https://rpg.ifi.uzh.ch/docs/Loquercio21_Science.pdf
[TRO 2022_Sun] Sihao Sun, Angel Romero, Philipp Foehn, Elia Kaufmann, Davide Scaramuzza, “A Comparative Study of Nonlinear MPC and Differential-Flatness-based Control for Quadrotor Agile Flight”, IEEE Transactions on Robotics, 2022,
PDF: https://rpg.ifi.uzh.ch/docs/Arxiv21_MPC_Sun.pdf
[RSS 2021_Bauersfeld] Leonard Bauersfeld, Elia Kaufmann, Philipp Foehn, Sihao Sun, Davide Scaramuzza, “NeuroBEM: Hybrid Aerodynamic Quadrotor Model”, RSS: Robotics, Science, and Systems, 2021,
PDF: https://rpg.ifi.uzh.ch/docs/RSS21_Bauersfeld.pdf
Matthias Faessler, Antonio Franchi, Davide Scaramuzza, “Differential Flatness of Quadrotor Dynamics Subject to Rotor Drag for Accurate Tracking of High-Speed Trajectories”, IEEE Robotics and Automation Letters, 2018.
PDF: https://rpg.ifi.uzh.ch/docs/RAL18_Faessler.pdf
Our research in Agile Drone Flight:
http://rpg.ifi.uzh.ch/aggressive_flight.html
Affiliations:
P. Foehn, E. Kaufmann, A. Romero, R. Penicka, S. Sun, L. Bauersfeld, T. Laengle, Y. Song, A. Loquercio, D. Scaramuzza are with the Robotics and Perception Group, University of Zurich, Switzerland
http://rpg.ifi.uzh.ch/
Music Credits: scottholmesmusic.com under Free Creative Commons License