Uploaded November 2026 | Updated November 2026, 3 hours ago
🌊🤖 Robotics Meets the Lighthouse!
For decades, lighthouse keepers on Qiliyu Island in the East China Sea have faced the challenges of isolation, harsh weather, and physically demanding work.
Now, DEEP Robotics is bringing a new kind of support to the island.
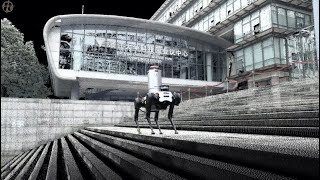
Our LYNX M20 wheeled-legged robot has arrived for real-world testing, exploring how robotic technology can assist with supply transportation, autonomous equipment inspections, and daily lighthouse operations.
From carrying essential supplies to supporting nighttime patrols, the LYNX M20 demonstrates how embodied intelligence can help people working in some of the most challenging environments.
💙 Technology moves forward, but it never forgets those who have stood watch for generations.
Discover more about DEEP Robotics:
https://www.deeprobotics.cn/en/
#DEEPRobotics #LYNXM20 #Lighthouse #Robotics #EmbodiedAI #SmartInspection
🌊🤖 Robotics Meets the Lighthouse!
For decades, lighthouse keepers on Qiliyu Island in the East China Sea have faced the challenges of isolation, harsh weather, and physically demanding work.
Now, DEEP Robotics is bringing a new kind of support to the island.
Our LYNX M20 wheeled-legged robot has arrived for real-world testing, exploring how robotic technology can assist with supply transportation, autonomous equipment inspections, and daily lighthouse operations.
From carrying essential supplies to supporting nighttime patrols, the LYNX M20 demonstrates how embodied intelligence can help people working in some of the most challenging environments.
💙 Technology moves forward, but it never forgets those who have stood watch for generations.
Discover more about DEEP Robotics:
https://www.deeprobotics.cn/en/
#DEEPRobotics #LYNXM20 #Lighthouse #Robotics #EmbodiedAI #SmartInspection