Uploaded September 2026 | Updated September 2026, 5 hours ago
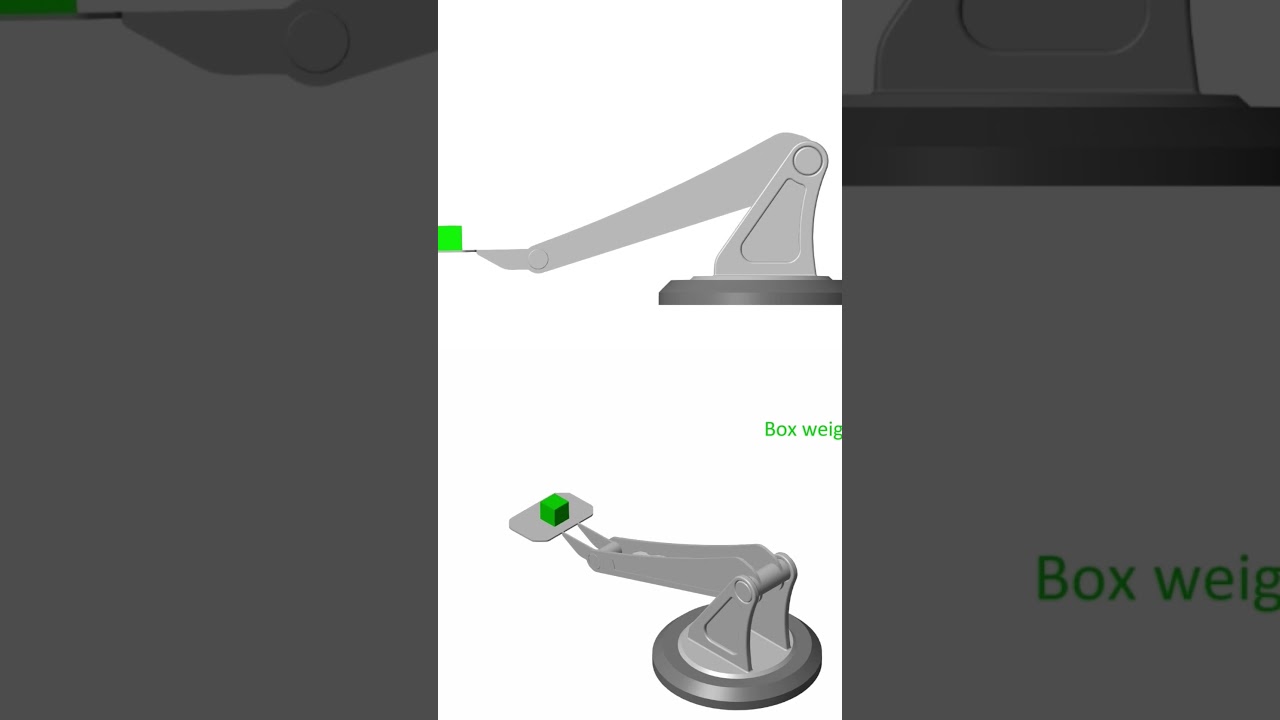
A 3-degree-of-freedom robotic arm modeled in MATLAB Simscape Multibody environment; the leveling behavior under dynamic loading was analyzed using PID-based torque control, an electronic parallelogram method to keep the platform horizontal, and real contact physics (contact dynamics) for the box–platform interaction.
#engineers #engineering #technology #algorithms
#controlsystems #softwareengineering #controltheory
#github #mathematics #matlab #coding #robotics
#automation #dynamics #mechanics #systems #modeling
#science #research #simulation #cad #robot #python
#physics #maths #control #code #software #vibration
#pendulum MathWorks SolidWorks Türkiye SOLIDWORKS
Muhammad Mudassir
A 3-degree-of-freedom robotic arm modeled in MATLAB Simscape Multibody environment; the leveling behavior under dynamic loading was analyzed using PID-based torque control, an electronic parallelogram method to keep the platform horizontal, and real contact physics (contact dynamics) for the box–platform interaction.
#engineers #engineering #technology #algorithms
#controlsystems #softwareengineering #controltheory
#github #mathematics #matlab #coding #robotics
#automation #dynamics #mechanics #systems #modeling
#science #research #simulation #cad #robot #python
#physics #maths #control #code #software #vibration
#pendulum MathWorks SolidWorks Türkiye SOLIDWORKS
Muhammad Mudassir


