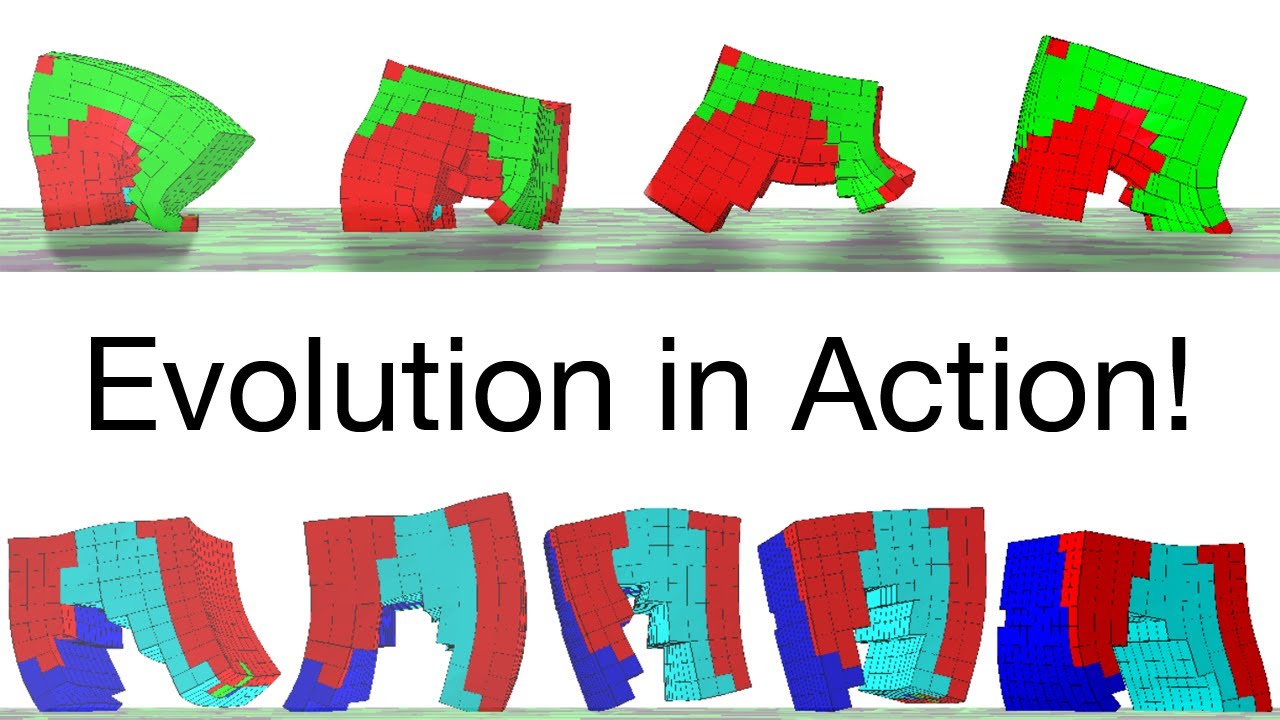
Evolving Soft Robots with Multiple Materials (muscle, bone, etc.) Evolving AI Lab 2013-04-04 | More videos: http://jeffclune.com/videos.htmlHere we evolve the bodies of soft robots made of multiple materials (muscle, bone, & support tissue) to move quickly. Evolution produces a diverse array of fun, wacky, interesting, but ultimately functional soft robots. Enjoy!This video accompanies the following paper: Unshackling Evolution: Evolving Soft Robots with Multiple Materials and a Powerful Generative Encoding. Cheney, MacCurdy, Clune, & Lipson. Proceedings of the Genetic and Evolutionary Computation Conference. 2013. PDF: http://jeffclune.com/publications/2013_Softbots_GECCO.pdfThe work was performed by members of the Cornell Creative Machines Lab: http://creativemachines.cornell.edu and the Evolving Artificial Intelligence Lab at the University of Wyoming: http://JeffClune.comThe simulator we used is called VoxCad, by Jon Hiller: http://www.VoxCad.com
Open-ended and AI-generating Algorithms in the Era of Foundation Models: Research Talk by Jeff Clune Evolving AI Lab 2023-10-11 | Foundation models (e.g. large language models) create exciting new opportunities in our longstanding quests to produce open-ended and AI-generating algorithms. In this talk I will share some of our recent work harnessing the power of foundation models to make progress in these areas. I will cover three of our more recent papers: (1) OMNI: Open-endedness via Models of human Notions of Interestingness, (2) Video Pre-Training (VPT), and (3) Thought Cloning: Learning to Think while Acting by Imitating Human Thinking. This research talk was given virtually as a keynote to the 6th International Workshop on Intrinsically Motivated Open-ended Learning (IMOL 2023) in Paris. For more, please see JeffClune.com or @jeffclune on Twitter.
ICML 2019 Tutorial: Recent Advances in Population-Based Search for Deep Neural Networks Evolving AI Lab 2019-06-17 | Recent Advances in Population-Based Search for Deep Neural Networks: Quality Diversity, Indirect Encodings, and Open-Ended Algorithms.Jeff Clune · Joel Lehman · Kenneth StanleyWe will cover new, exciting, unconventional techniques for improving population-based search. These ideas are already enabling us to solve hard problems. They also hold great promise for further advancing machine learning, including deep neural networks. Major topics covered include (1) explicitly searching for behavioral diversity (in a low-dimensional space where diversity is inherently interesting, such as the behavior of robots, rather than in the true search space, such as the weights of the DNN that controls the robot), especially Quality Diversity algorithms, which have produced state-of-the-art results in robotics and solved a version of the hard-exploration RL challenge of Montezuma’s Revenge; (2) open-ended search, wherein algorithms continually create new and increasingly complex capabilities without bound, for example by simultaneously inventing new challenges and their solutions; and (3) indirect encoding (e.g. HyperNEAT/HyperNetworks), wherein one network encodes how to construct a larger neural network or learning system. The idea is motivated by biological development, wherein a search in the space of a few thousand genes enables the specification of a trillion-connection brain and its learning algorithm. We conclude with a discussion on current and future hybrids of traditional machine learning with these ideas, including how augmenting meta-learning with them offers an alternative path to our most ambitious AI goals.Slides: http://jeffclune.com/publications/2019_06_10_ICML_Tutorial-PopulationBasedMethods.pdf
Deep Curiosity Search: Seaquest (Best) Evolving AI Lab 2018-08-30 | Our best agent produced by Curiosity Search on the Atari game Seaquest. This agent achieves approximately 132,000 points, which is superior to that of many other Deep RL algorithms like DQN, A2C, and Rainbow (however, not quite as good as Ape-X). This score is also vastly greater than what an average human can achieve!The "curiosity grid", which logs the agent's exploration of the game world, is shown on right. Curiosity Search rewards agents for visiting as many of these locations (the white squares) as possible over the course of the game. Each time the agent starts a new game, the curiosity grid is reset such that "everything is new" again.Because the agent is rewarded for exploring the entire world in every new game, we say that Curiosity Search encourages "intra-life" exploration, as opposed to the training-wide approaches to exploration used by in most other exploration methods.In this video, the agent explores the entire curiosity grid very quickly in its lifetime; once the grid is filled out (completely white), Curiosity Search can provide no further rewards to the agent since everything has already been explored. It is interesting that even this brief exploration bonus of Curiosity Search can improve performance by such a large magnitude!
Deep Curiosity Search: Seaquest Evolving AI Lab 2018-08-30 | A typical agent produced by Curiosity Search on the Atari game Seaquest. This agent achieves approximately 3400 points, which is double that of other popular Deep RL algorithms like DQN and A2C, although this score is superseded by more recent algorithms like Rainbow and Ape-X.The "curiosity grid", which logs the agent's exploration of the game world, is shown on right. Curiosity Search rewards agents for visiting as many of these locations (the white squares) as possible over the course of the game. Each time the agent starts a new game, the curiosity grid is reset such that "everything is new" again.Because the agent is rewarded for exploring the entire world in every new game, we say that Curiosity Search encourages "intra-life" exploration, as opposed to the training-wide approaches to exploration used by in most other exploration methods.In this video, the agent explores the entire curiosity grid very quickly in its lifetime; once the grid is filled out (completely white), Curiosity Search can provide no further rewards to the agent since everything has already been explored. It is interesting that even this brief exploration bonus of Curiosity Search can still improve performance!
Deep Curiosity Search: Montezumas Revenge (Best) Evolving AI Lab 2018-08-30 | Our best agent produced by Curiosity Search on the very challenging Atari game Montezuma's Revenge. This agent achieves 6600 points and explores many rooms, whereas most popular Deep RL algorithms like DQN, A2C, and Rainbow struggle to even pick up the first key.The "curiosity grid", which logs the agent's exploration of the game world, is shown on right. Curiosity Search rewards agents for visiting as many of these locations (the white squares) as possible over the course of the game. Each time the agent starts a new game, the curiosity grid is reset such that "everything is new" again.Because the agent is rewarded for exploring the entire world in every new game, we say that Curiosity Search encourages "intra-life" exploration, as opposed to the training-wide approaches to exploration used by in most other exploration methods.
Deep Curiosity Search: Montezumas Revenge Evolving AI Lab 2018-08-30 | A typical agent produced by Curiosity Search on the very challenging Atari game Montezuma's Revenge. This agent achieves 3500 points and explores many rooms, whereas most popular Deep RL algorithms like DQN, A2C, and Rainbow struggle to even pick up the first key.The "curiosity grid", which logs the agent's exploration of the game world, is shown on right. Curiosity Search rewards agents for visiting as many of these locations (the white squares) as possible over the course of the game. Each time the agent starts a new game, the curiosity grid is reset such that "everything is new" again.Because the agent is rewarded for exploring the entire world in every new game, we say that Curiosity Search encourages "intra-life" exploration, as opposed to the training-wide approaches to exploration used by in most other exploration methods.
Robotics task CMOEA and NSGA-II after 75000 generations [Supplementary material] Evolving AI Lab 2018-07-11 | Supplementary material to: Evolving Multimodal Robot Behavior via Many Stepping Stones with the Combinatorial Multi-Objective Evolutionary AlgorithmThis videos shows the 4 best champions out of 30 runs for CMOEA and Combined-Target NSGA-II, both with and without selection for genotypic and phenotypic modularity. Champions were selected after 75000 generations of evolution. Due to differences in machine architecture between the computers that ran the simulation and the computer that did the rendering, the behaviors shown do not necessarily result in the reported fitness.Authors: Joost Huizinga and Jeff CluneThe full paper is available here: www.evolvingai.org/cmoeaFull cite: J. Huizinga and J. Clune. "Evolving Multimodal Robot Behavior via Many Stepping Stones with the Combinatorial Multi-Objective Evolutionary Algorithm." arXiv preprint arXiv:1807.03392 (2018).
Maze navigation task [Supplementary material] Evolving AI Lab 2018-07-11 | Supplementary material to: Evolving Multimodal Robot Behavior via Many Stepping Stones with the Combinatorial Multi-Objective Evolutionary AlgorithmThis videos shows the behavior of the best individual from the median (rounded up) performing run out of 30 runs on the maze navigation task for each of the following treatments: CMOEA, Single Bin CMOEA, NSGA-II, Combined-Target NSGA-II, Lexicase Selection, Combined-Target Lexicase Selection. The video show the behavior on both the test set and the training set. Individuals are shown after 1000 generations of evolution.Authors: Joost Huizinga and Jeff CluneThe full paper is available here: www.evolvingai.org/cmoeaFull cite: J. Huizinga and J. Clune. "Evolving Multimodal Robot Behavior via Many Stepping Stones with the Combinatorial Multi-Objective Evolutionary Algorithm." arXiv preprint arXiv:1807.03392 (2018).
Robotics task main treatments after 15000 generations [Supplementary material] Evolving AI Lab 2018-07-11 | Supplementary material to: Evolving Multimodal Robot Behavior via Many Stepping Stones with the Combinatorial Multi-Objective Evolutionary AlgorithmThis videos shows the 4 best champions out of 30 runs for each of the main treatments: CMOEA, Single Bin CMOEA, Combined-Target NSGA-II, Combined-Target Lexicase Selection. Champions were selected after 15000 generations of evolution.Due to differences in machine architecture between the computers that ran the simulation and the computer that did the rendering, the behaviors shown do not necessarily result in the reported fitness.Authors: Joost Huizinga and Jeff CluneThe full paper is available here: www.evolvingai.org/cmoeaFull cite: J. Huizinga and J. Clune. "Evolving Multimodal Robot Behavior via Many Stepping Stones with the Combinatorial Multi-Objective Evolutionary Algorithm." arXiv preprint arXiv:1807.03392 (2018).
The artificial intelligence developed to identify and count wild animals Evolving AI Lab 2018-06-30 | Our recent PNAS paper on BBC newshttp://www.pnas.org/content/115/25/E5716
What is Deep Learning? How will it Change the World? Evolving AI Lab 2017-10-26 | A talk by Jeff Clune describing artificial intelligence (AI), specifically deep learning (aka deep neural networks), and how it will change the world, especially economically. Note: this talk purposefully emphasized the contributions of Jeff's lab (the EvolvingAI Lab at the University of Wyoming) because it was for a Wyoming audience interested in hearing about work in this area being done within the state (and funded in part by the state). I apologize for all the amazing work I was not able to mention by others!
KUKA Greeting Robot - Automatic Facial Recognition via Deep Learning by a KUKA Robot Evolving AI Lab 2017-10-05 | A demonstration of the robotics project by Richard Ruiqi Yang, in which he trained a deep neural network running on a KUKA robot to greet the members of the Evolving AI Lab.
Aligning Phenotypic and Genotypic Modularity [Supplementary material] Evolving AI Lab 2017-04-27 | Supplementary material to: Does Aligning Phenotypic and Genotypic Modularity Improve the Evolution of Neural Networks?This videos shows the 5 best champions from 30 runs on the robotics task for the treatments with direct selection for both genotypic and phenotypic modularity (PMOD+GMOD). Champions were selected after 5000 generations of evolution.Authors: Joost Huizinga, Jean-Baptiste Mouret, and Jeff CluneThe full paper is available here: www.evolvingai.org/ModularAlignmentFull cite: J. Huizinga, J.-B. Mouret, and J. Clune. "Does Aligning Phenotypic and Genotypic Modularity Improve the Evolution of Neural Networks?" In Proceedings of the Genetic & Evolutionary Computation Conference. ACM, 2016.
PPGN: Sampling between 10 classes Evolving AI Lab 2016-12-01 | Sampling chain from Plug and Play Generative Networks between 10 different classes. The video shows 1 sample per frame with no frames filtered out.Paper: Nguyen A, Yosinski J, Bengio Y, Dosovitskiy A, Clune J (2016). Plug & Play Generative Networks: Conditional Iterative Generation of Images in Latent Space. arXiv 1738978More info: http://www.evolvingai.org/ppgn
PPGN: Sampling within a single class of Junco Evolving AI Lab 2016-12-01 | Sampling chain from Plug and Play Generative Networks within the Junco (a type of bird) class. The video shows 1 sample per frame with no frames filtered out.Paper: Nguyen A, Yosinski J, Bengio Y, Dosovitskiy A, Clune J (2016). Plug & Play Generative Networks: Conditional Iterative Generation of Images in Latent Space. arXiv 1738978More info: www.evolvingai.org/ppgn
PPGN: Sampling within a single class of Triumph Arch Evolving AI Lab 2016-12-01 | Sampling chain from Plug and Play Generative Networks within the Triumph Arch class. The video shows 1 sample per frame with no frames filtered out.Paper: Nguyen A, Yosinski J, Bengio Y, Dosovitskiy A, Clune J (2016). Plug & Play Generative Networks: Conditional Iterative Generation of Images in Latent Space. arXiv 1738978More info: www.evolvingai.org/ppgn
Visualizations of output class neurons of CaffeNet throughout training - NIPS 2016 Evolving AI Lab 2016-10-28 | Supplementary video accompanying our NIPS 2016 paper: Nguyen A, Dosovitskiy A, Yosinski J, Brox T, Clune J (2016) Synthesizing the preferred inputs for neurons in neural networks via deep generator networks. NIPS 29More info: http://evolvingai.org/synthesizing
Synthesizing videos for an activity classification network (LRCN) - NIPS 2016 Evolving AI Lab 2016-10-28 | Supplementary video accompanying our NIPS 2016 paper: Nguyen A, Dosovitskiy A, Yosinski J, Brox T, Clune J (2016) Synthesizing the preferred inputs for neurons in neural networks via deep generator networks. NIPS 29More info: http://evolvingai.org/synthesizingHere, we synthesize videos for LRCN—an activity recognition model made available by Donahue et al. [1]. The model combines a convolutional neural network (for feature extraction from each frame), and a LSTM recurrent network [1]. It was trained to classify videos into 101 classes of human activities in the UCF-101 dataset.[1] Donahue et al. (2015). Long-term recurrent convolutional networks for visual recognition and description. CVPR 2015
Visualizations of neurons at all 8 layers of CaffeNet throughout training - NIPS 2016 Evolving AI Lab 2016-10-28 | Supplementary video accompanying our NIPS 2016 paper:Nguyen A, Dosovitskiy A, Yosinski J, Brox T, Clune J (2016) Synthesizing the preferred inputs for neurons in neural networks via deep generator networks. NIPS 29More info: http://evolvingai.org/synthesizing
Talk: Robots that can adapt like animals Evolving AI Lab 2016-08-05 | Talk by Jean-Baptiste Mouret on the nature paper "Robots that can adapt like animals" held at GECCO 2016.Our apologies for the low volume and the background noise, this presentation was recorded without an external microphone.Full citation: Cully A, Clune, J, Tarapore D, Mouret J-B (2015). Robots that can adapt like animals. Nature, 521(7553), 503-507.
Evolving a Single Modular Robot Brain to Perform Six Different Tasks Evolving AI Lab 2016-08-04 | This is our entry to the GECCO 2016 Virtual Creatures Competition. It received the honorable mention for technical achievement.The video is based on the following paper: Huizinga J, Mouret J-B, Clune J (2016) Does aligning phenotypic and genotypic modularity improve the evolution of neural networks? Proceedings of the Genetic and Evolutionary Computation Conference. 125-132
Talk: Does aligning genotypic and phenotypic modularity improve the evolution of neural networks? Evolving AI Lab 2016-08-04 | This is a talk by Joost Huizinga of the paper "Does aligning genotypic and phenotypic modularity improve the evolution of neural networks?" held at the GECCO 2016 conference. Full citation: Huizinga J, Mouret J-B, Clune J (2016) Does aligning phenotypic and genotypic modularity improve the evolution of neural networks? Proceedings of the Genetic and Evolutionary Computation Conference. 125-132
Deep Learning Overview & Visualizing What Deep Neural Networks Learn Evolving AI Lab 2016-04-24 | Jeff Clune introduces deep learning, describes how it is changing many fields of science and sectors of the economy, and then describes the work he has been involved in regarding how to visualize what feature each neuron in a neural network has learned to detect. For all of the papers, source code, and more video research summaries, see http://EvolvingAI.orgNote: almost all of this work was done by Anh Nguyen, a member of the Evolving AI Lab at the University of Wyoming. It was also all done in collaboration with Jason Yosinski of Cornell University. Congrats to both of them on the fantastic work!
Neural modularity helps organisms evolve to learn new skills without forgetting old skills Evolving AI Lab 2015-04-02 | Video summary of Ellefsen, Mouret, and Clune (2015) Neural modularity helps organisms evolve to learn new skills without forgetting old skills. PLoS Computational Biology. Summary: A long-standing goal in artificial intelligence (AI) is creating computational brain models (neural networks) that learn what to do in new situations. An obstacle is that agents typically learn new skills only by losing previously acquired skills. Here we test whether such forgetting is reduced by evolving modular neural networks, meaning networks with many distinct subgroups of neurons. Modularity intuitively should help because learning can be selectively turned on only in the module learning the new task. We confirm this hypothesis: modular networks have higher overall performance because they learn new skills faster while retaining old skills more. Our results suggest that one benefit of modularity in natural animal brains may be allowing learning without forgetting.Abstract: A long-standing goal in artificial intelligence is creating agents that can learn a variety of different skills for different problems. In the artificial intelligence subfield of neural networks, a barrier to that goal is that when agents learn a new skill they typically do so by losing previously acquired skills, a problem called catastrophic forgetting. That occurs because, to learn the new task, neural learning algorithms change connections that encode previously acquired skills. How networks are organized critically affects their learning dynamics. In this paper, we test whether catastrophic forgetting can be reduced by evolving modular neural networks. Modularity intuitively should reduce learning interference between tasks by separating functionality into physically distinct modules in which learning can be selectively turned on or off. Modularity can further improve learning by having a reinforcement learning module separate from sensory processing modules, allowing learning to happen only in response to a positive or negative reward. In this paper, learning takes place via neuromodulation, which allows agents to selectively change the rate of learning for each neural connection based on environmental stimuli (e.g. to alter learning in specific locations based on the task at hand). To produce modularity, we evolve neural networks with a cost for neural connections. We show that this connection cost technique causes modularity, confirming a previous result, and that such sparsely connected, modular networks have higher overall performance because they learn new skills faster while retaining old skills more and because they have a separate reinforcement learning module. Our results suggest (1) that encouraging modularity in neural networks may help us overcome the long-standing barrier of networks that cannot learn new skills without forgetting old ones, and (2) that one benefit of the modularity ubiquitous in the brains of natural animals might be to alleviate the problem of catastrophic forgetting.Sources of the media used in this video:Background music: The Passion HiFi - Redemptionsoundcloud.com/freehiphopbeatsforyou/free-the-passion-hifiImages:Brain Zoom to neurons: www.dreamstime.comChess player: Flickr commons, by Jeffrey BarkeSoccer player: Wikimedia Commons, by AFP/SCANPIThinking robot: Pixabay, by DrSJSVacuum cleaner: Pixabay, by NemoMonkey with stick: Wikimedia Commons, by Mike RCheetah robot: Boston DynamicsRobot in rocky terrain: Flickr commons, by JBLM PAO
Deep Neural Networks are Easily Fooled Evolving AI Lab 2014-12-16 | A video summary of the paper: Nguyen A, Yosinski J, Clune J. Deep Neural Networks are Easily Fooled: High Confidence Predictions for Unrecognizable Images. In Computer Vision and Pattern Recognition (CVPR '15), IEEE, 2015.The paper is available here: http://EvolvingAI.org/foolingSpecial thanks to those who created the music, images, videos and software that were used to create this video.Music: Meet FrancisArtist: SemaphoreNewgrounds Audio Portal - http://www.newgrounds.com/audioSound effects fromFreeSoundwww.freesound.orgImages from:Woman and thief charactershttp://www.goanimate.comSchool busSzegedy et. al. 2013 - Intriguing Properties of Neural NetworksGuitarsILSVRC 2012 datasetStarfishhttp://en.wikipedia.org/wiki/File:Starfish,_Mauritius.jpgReal handwritten digits 0-9MNIST dataset Evolved images by humans - Parrot, Race car, SeaPicBreeder.orgDarwin's facehttp://the-philosophers-stone.comLaptophttp://clipartpanda.com
Talk summarizing Evolving Neural Networks That Are Both Modular and Regular Evolving AI Lab 2014-09-17 | Talk summarizing the paper Evolving Neural Networks That Are Both Modular and Regular: HyperNEAT Plus the Connection Cost Technique. Talk given by Joost Huizinga at the 2014 GECCO Conference in Vancouver, British Columbia.Full pdf available here: http://www.evolvingai.org/publicationsAnimated, 5-minute summary available here: youtube.com/watch?v=t15wUkCXuxQ
The Laramie Robotics Club Evolving AI Lab 2014-09-06 | More info: http://www.laramieroboticsclub.orgCome have fun playing with robots! It's free. Any high-school students and middle-school students interested in learning how to program robots should join the fun.
Talk summarizing Encouraging Creative Thinking in Robots... Evolving AI Lab 2014-08-31 | Talk summarizing the paper Encouraging Creative Thinking in Robots Improves Their Ability to Solve Challenging Problems. Talk given by Jingyu Li at the 2014 GECCO Conference in Vancouver, British Columbia.YouTube video Summary: youtube.com/watch?v=xik92wK8_gMFurther information regarding this work as well as a link to the PDF can be found at: http://www.EvolvingAI.com
Talk summarizing Novelty Search Creates Robots with General Skills for Exploration Evolving AI Lab 2014-08-18 | Talk summarizing the paper Novelty Search Creates Robots with General Skills for Exploration. Talk given by Roby Velez at the 2014 GECCO Conference in Vancouver, British Columbia.YouTube video Summary: youtube.com/watch?v=P-EqOBqjTyUFurther information regarding this work as well as a link to the PDF can be found at: http://www.EvolvingAI.com
Encouraging Creative Thinking in Robots: The Creative Thinking Approach Evolving AI Lab 2014-05-16 | A video summary of the paper: Jingyu Li, Jed Storie, Jeff Clune (2014) "Encouraging Creative Thinking in Robots Improves Their Ability to Solve Challenging Problems," Proceedings of the Genetic and Evolutionary Computation Conference.The paper is available here: http://EvolvingAI.com/Special thanks to those who created the music, images, and videos that were used to create this video.Music: Shooting starArtist: David PalmeroJamendo -- http://www.jamendo.comIn order of appearance:Rainforest animals video clip from:youtube.com/watch?v=uXkW1OEVjGENeurons (human robot comparison) image from:http://pulpbits.comArtificial neural network (human robot comparison) image from:http://www-d0.fnal.govNeurons video clip from:youtube.com/watch?v=vyNkAuX29OUScribbler robot image from:http://www.parallax.comHuman thinking (human v. robot cognition) image from:http://www.clipartbest.comCartoon robot (human v. robot cognition) image from:http://mommyspeakschinese.comDuck image from:Microsoft clipartGlass bottle image from:http://www.couronneco.comPeanut image from:http://www.whatcanipaint.comTwig image from:http://www.wykop.pl/Grass image from:http://commons.wikimedia.orgPebble image from:http://background-pictures.vidzshare.netLight bulb image from:http://www.clipartbest.comRobot with light bulb image from:http://robotfilmfestival.comCreative thinking summary image from:http://ignitethebox.com
Automated Generation of Environments to Test the General Learning Capabilities of AI Agents Evolving AI Lab 2014-04-29 | A video summary of the paper:Coleman O, Blair A, Clune J (2014) Automated Generation of Environments to Test the General Learning Capabilities of AI Agents. Proceedings of the Genetic and Evolutionary Computation Conference.PDF: http://goo.gl/GCnkQ0Abstract: Algorithms for evolving agents that learn during their lifetime have typically been evaluated on only a handful of environments. Designing such environments is labour intensive, potentially biased, and provides only a small sample size that may prevent accurate general conclusions from being drawn. In this paper we introduce a method for automatically generating MDP environments which allows the difficulty to be scaled in several ways. We present a case study in which environments are generated that vary along three key dimensions of difficulty: the number of environment configurations, the number of available actions, and the length of each trial. The study reveals interesting differences between three neural network models -- Fixed-Weight, Plastic-Weight, and Modulated Plasticity -- that would not have been obvious without sweeping across these different dimensions. Our paper thus introduces a new way of conducting reinforcement learning science: instead of manually designing a few environments, researchers will be able to automatically generate a range of environments across key dimensions of variation. This will allow scientists to more rigorously assess the general learning capabilities of an algorithm, and may ultimately improve the rate at which we discover how to create AI with general purpose learning.
Novelty Search Creates Robots with General Skills for Exploration Evolving AI Lab 2014-04-25 | A video summary of the paper: Velez R, Clune J (2014) Novelty Search Creates Robots with General Skills for Exploration. Proceedings of the Genetic and Evolutionary Computation Conference.The paper is available here: http://EvolvingAI.com/Special thanks to those who created the music and videos used to make this video.Music: Aunties LullabyComposer: Pete HawkesFound at: http://www.freeplaymusic.com/volumedetail.aspx?volume=1822Animal clips:Horses: youtube.com/watch?v=_KrAMPHdCK4Frigate: youtube.com/watch?v=NFBhaStJebAOrangutan: youtube.com/watch?v=Umxw5tpgBSUWhale: http://vimeo.com/77314166
Evolving Artificial Neural Networks That Are Both Modular and Regular Evolving AI Lab 2014-04-23 | A video summary of the paper: Huizinga, J, Mouret JB, Clune J (2014) Evolving Neural Networks That Are Both Modular and Regular: HyperNeat Plus the Connection Cost Technique. Proceedings of the Genetic and Evolutionary Computation Conference.The paper is available here: http://EvolvingAI.com/Special thanks to those who created the music, images, videos and software that were used to create this video.Music: Hidden gardenArtist: SemaphoreNewgrounds Audio Portal - http://www.newgrounds.com/audioBrain imaging from:Brain Explorer® 2 - ©2014 Allen Institute for Brain Science.Allen Human Brain Atlas [Internet]. Available from: http://human.brain-map.org/.Animated car engine from:Chomoka Studioshttp://chomoka.comImages from:Regular buildings:http://www.presidiacreative.comBrain zoom to neurons:http://www.dreamstime.comCaterpillar:http://www.wallpapergang.comThinking robot:http://www.hdiphonewallpapers.usFree price tag:veritra.comhttp://veritra.com/
Overview of the Evolving Artificial Intelligence Lab at the University of Wyoming Evolving AI Lab 2013-11-07 | A brief overview of the Evolving Artificial Intelligence Lab at the University of Wyoming, directed by Jeff Clune. The video summarizes some of the reasons we are interested in the field of Evolutionary Robotics, which seeks to ultimately evolve artificially intelligent robots that can rival natural animals in intelligence and agility.
Evolved Sensitive Periods in Learning Evolving AI Lab 2013-09-24 | A talk presented at ECAL 2013 by Kai Olav EllefsenThe paper is available for free at http://mitpress.mit.edu/sites/default/files/titles/content/ecal13/ch044.html
Costs and Benefits of Learning Evolving AI Lab 2013-09-18 | A talk presented at ECAL 2013 by Kai Olav EllefsenThe paper is available for free at http://mitpress.mit.edu/sites/default/files/titles/content/ecal13/978-0-262-31709-2-ch044.pdf
Why does modularity evolve? The evolutionary origins of modularity Evolving AI Lab 2013-03-29 | Engineered and evolved things are organized in modules (e.g. organs or car parts), yet why modularity evolves remains one of biology's most important open questions. This paper shows for the first time that modularity evolves not because it speeds up adaptation, as the leading theory holds, but because it saves on "wiring costs". Connections in biological networks have costs (e.g. building and maintaining them), and modular networks use fewer connections. These results help explain the ubiquitous modularity in biological networks, such as genetic modules and the neural modules in our brains, and will help scientists evolve smarter artificial intelligence. Interestingly, the modular networks that evolve do adapt faster, meaning that adaptation is a consequence of modularity, not its main cause.Cite: Clune J, Mouret J-B, Lipson H (2013) The evolutionary origins of modularity. Proceedings of the Royal Society B. 280: 20122863.Free PDF: http://jeffclune.com/publications/2013-CluneEtAl-EvolutionaryOriginsModularity-RoyalSociety.pdfMore information: http://jeffclune.com/modularity.htmlAbstract: A central biological question is how natural organisms are so evolvable (capable of quickly adapting to new environments). A key driver of evolvability is the widespread modularity of biological networks—their organization as functional, sparsely connected subunits—but there is no consensus regarding why modularity itself evolved. Although most hypotheses assume indirect selection for evolvability, here we demonstrate that the ubiquitous, direct selection pressure to reduce the cost of connections between network nodes causes the emergence of modular networks. Computational evolution experiments with selection pressures to maximize network performance and minimize connection costs yield networks that are significantly more modular and more evolvable than control experiments that only select for performance. These results will catalyse research in numerous disciplines, such as neuroscience and genetics, and enhance our ability to harness evolution for engineering purposes.
Evolving artificial neural networks with generative encodings inspired by developmental biology Evolving AI Lab 2013-02-18 | In this dissertation I (Jeff Clune) investigate the difference between generative encodings and direct encodings for evolutionary algorithms. Generative encodings are inspired by developmental biology and were designed, in part, to increase the regularity of synthetically evolved phenotypes. Regularity is an important design principle in both natural organisms and engineered designs. The majority of this dissertation focuses on how the property of regularity enables a generative encoding to outperform direct encoding controls, and whether a bias towards regularity also hurts the performance of the generative encoding on some problems. I also report on whether researchers can bias the types of regularities produced by a generative encoding to accommodate user preferences. Finally, I study the degree to which a generative encoding produces another important design principle, modularity.Several previous studies have shown that generative encodings outperform direct encodings on highly regular problems. However, prior to this dissertation, it was not known how generative encodings compare to direct encodings on problems with different levels of regularity. On three different problems, I show that a generative encoding can exploit intermediate amounts of problem regularity, which enabled the generative encoding to increasingly outperform direct encoding controls as problem regularity increased. This performance gap emerged because the generative encoding produced regular artificial neural networks (ANNs) that produced regular behaviors. The ANNs evolved with the generative encoding contained a diverse array of complicated, regular neural wiring patterns, whereas the ANNs produced by a direct encoding control were irregular.I also document that the bias towards regularity can hurt a generative encoding on problems that have some amount of irregularity. I propose a new algorithm, called HybrID, wherein a generative encoding produces regular patterns and a direct encoding modifiesthose patterns to provide fitness-enhancing irregularities. HybrID outperformed a generative encoding alone on three problems for nearly all levels of regularity, which raises the question of whether generative encodings may ultimately excel not as stand-alone algorithms, but by being hybridized with a further process of irregular refinement.The results described so far document that a generative encoding can produce regular solutions. I then show that, at least for the generative encoding in this case study, it is possible to influence the types of regularities produced, which allows domain knowledge and preferences to be injected into the algorithm. I also investigated whether the generative encoding can produce modular solutions. I present the first documented case of this generative encoding producing a modular phenotype on a simple problem. However, the generative encoding's inability to create modularity on harder problems where modularity would have been beneficial suggests that more work is needed to increase the likelihood that this encoding produces modular ANNs in response to challenging, decomposable problems.Overall, this dissertation paints a more complete picture of generative encodings than prior studies. Initially, it demonstrates that, by producing regular ANNs and behaviors, generative encodings increasingly outcompete direct encodings as problem regularity increases. It next documents that a bias towards regularity can harm the performance of direct encodings when problems contain irregularities. The HybrID algorithm suggests a path forward, however, by revealing that a refinement process that fine-tunes the regular patterns produced by a generative encoding can boost performance by accounting for problem irregularities. Finally, the dissertation shows that the generative encoding studied can produce modular networks on simple problems, but may struggle to do so on harder problems. The general conclusion that can be drawn from this work is that generative encodings can produce some of the properties seen in complex, natural organisms, and will likely be an important part of our long-term goal of synthetically evolving phenotypes that approach the capability, intelligence, and complexity of their natural rivals.
Multi-Objective Landscape Exploration (MOLE) algorithm. Explore all areas of your fitness landscape Evolving AI Lab 2013-02-18 | Read a two-page abstract here: Here we introduce an algorithm to compute phenotype-fitness maps as a way to understand the relationship between phenotypic dimensions and fitness. The central idea is to explicitly select for fit organisms in all areas of a phenotype landscape, where the axes of that landscape are defined by phenotypic dimensions of interest. To produce such maps, we introduce the Multi-Objective Landscape Exploration (MOLE) algorithm, which is a multi-objective evolutionary algorithm, specifically NSGA-II (Deb, 2001), with two objectives: (1) searching for new organisms that are far from solutions already generated, with distance measured in a Cartesian space defined by the key dimensions, and (2) generating highly fit organisms. With MOLE, scientists can see how fitness changes as a function of various phenotypic dimensions (Figure 1). This combination of a fitness objective and an archive-based exploration objective is similar to "novelty-based multi-objectivization" (Mouret, 2011; Lehman and Stanley, 2011), but is used to generate phenotype-fitness maps instead of producing highly fit solutions.
Golem Project: Evolve virtual creatures and 3D print them to walk in the real world Evolving AI Lab 2013-02-11 | A shorter video of the famous Golem Project (Lipson & Pollack, Nature, 2000). They evolved virtual creatures in a computer and then 3D printed them. After snapping in the motors, the creatures walked in the real world. Featured on the cover of the New York Times. Here is the scientific publication: http://creativemachines.cornell.edu/papers/Nature00_Lipson.pdfHod Lipson was my (Jeff Clune's) postdoc advisor at Cornell University.If you like this, you'll also like this: http://www.youtube.com/watch?v=z9ptOeByLA4
Evolving Modular Networks: Video for The Evolutionary Origins of Modularity Evolving AI Lab 2013-01-31 | Video for the following paper:Clune J, Baptiste-Mouret J-B, Lipson H (2013) The evolutionary origins of modularity. Proceedings of the Royal Society. 280: 20122863.For more information, and a PDF of the paper, see: http://jeffclune.com
Evolving Gaits for Physical Robots Directly in Hardware with the HyperNEAT Generative Encoding Evolving AI Lab 2012-11-06 | Some of the gaits evolved by the HyperNEAT algorithm for the following paper: Yosinski J, Clune J, Hidalgo D, Nguyen S, Cristobal Zagal J, Lipson H (2011) Evolving robot gaits in hardware: the HyperNEAT generative encoding vs. parameter optimization. Proceedings of the European Conference on Artificial Life. 890-897.A copy of the paper and better gaits that were evolved first in simulation and then transferred to this robot are available at:http://creativemachines.cornell.edu/evolved-quadruped-gaitsorJeffClune.com
Evolving Gaits for Legged Robots: Neural Networks with Geometric Patterns Perform Better Evolving AI Lab 2012-10-21 | Neural networks evolved to produce gaits for legged robots. The use of the HyperNEAT generative encoding produces geometric patterns (regularities) in the neural wiring of the evolved brains, which improves performance by producing coordinated, regular leg movements. Visit JeffClune.com for more information, including the publications that describe this research. A video describing how this work was done is here: http://www.youtube.com/watch?v=Tx1G4BNd4dw&feature=relmfuEvolving artificial neural networks (ANNs) and gaits for robots are difficult, time-consuming tasks for engineers, making them suitable for evolutionary algorithms (aka genetic algorithms). Generative encodings (aka indirect and developmental encodings) perform better than direct encodings by producing neural regularities that result in behavioral regularities.References: • Clune J, Stanley KO, Pennock RT, Ofria C (2011) On the performance of indirect encoding across the continuum of regularity. IEEE Transactions on Evolutionary Computation. 15(3): 346-367.• Clune J, Beckmann BE, Ofria C, and Pennock RT (2009) Evolving coordinated quadruped gaits with the HyperNEAT generative encoding. Proceedings of the IEEE Congress on Evolutionary Computing. 2762-2771.• Yosinski J, Clune J, Hidalgo D, Nguyen S, Cristobal Zagal J, Lipson H (2011) Evolving robot gaits in hardware: the HyperNEAT generative encoding vs. parameter optimization. Proceedings of the European Conference on Artificial Life. 890-897.• Lee S, Yosinski J, Glette K, Lipson H, Clune J (2013) Evolving robot gaits for physical robots with generative encodings: the benefits of simulation. In preparation.Please contact Jeff Clune by visiting the Contact page at http://JeffClune.com
Evolving Regular, Modular Neural Networks Evolving AI Lab 2012-09-24 | I (Jeff Clune) summarize my research into evolving modular, regular neural networks, which are digital models of brains. The property of regularity is produced by using HyperNEAT, a generative encoding based on concepts from developmental biology [1]. The property of modularity arises because we add a cost for connections between neurons in the network [2]. Evolving structurally organized neural networks, including those that are regular and modular, is a necessary step in our long-term quest of evolving computational intelligence that rivals or surpasses human intelligence.For more information, including all of my publications, press articles about my work, and additional videos, please visit JeffClune.com and subscribe to this channel. For infrequent updates about my research and to ask or discuss questions about it, please subscribe to the JeffCluneResearch Google Group at http://goo.gl/DJ1wK[1] Clune J, Stanley KO, Pennock RT, Ofria C (2011) On the performance of indirect encoding across the continuum of regularity. IEEE Transactions on Evolutionary Computation. 15(3): 346-367. PDF: http://goo.gl/qYHPR[2] Clune J, Baptiste-Mouret J-B, Lipson H (2012) The evolutionary origins of modularity. ArXiv. 1207.2743v1. PDF: http://arxiv.org/pdf/1207.2743v1.pdf
EndlessForms.com - Design objects with evolution and 3D print them! Evolving AI Lab 2011-08-17 | On http://EndlessForms.com objects are evolved in the same way that plants and animals are bred. You pick the ones you like and they become the parents of the next generation of objects. As in biological evolution, the offspring look similar, but not identical, to their parents, allowing you to explore different designs. Under the hood, there is an evolutionary process in which the genomes of parents are mutated and crossed over to produce new offspring objects. Additionally, the objects are grown from their genomes similar to how a single fertilized egg grows into a jaguar, hawk, or human. This grounding in developmental biology enables the evolution of complex, natural-looking forms. For more info visit: http://endlessforms.com/about_the_technology
EndlessForms.com - Design objects with evolution and 3D print them! (longer video) Evolving AI Lab 2011-06-17 | On EndlessForms.com objects are evolved in the same way that plants and animals are bred. You pick the ones you like and they become the parents of the next generation of objects. As in biological evolution, the offspring look similar, but not identical, to their parents, allowing you to explore different designs. Under the hood, there is an evolutionary process in which the genomes of parents are mutated and crossed over to produce new offspring objects. Additionally, the objects are grown from their genomes similar to how a single fertilized egg grows into a jaguar, hawk, or human. This grounding in developmental biology enables the evolution of complex, natural-looking forms.