Uploaded May 2025 | Updated September 2026, 2 days ago
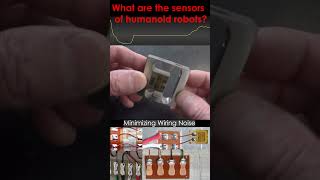
In advanced robotics, strain gage–based force and torque sensors are foundational. These sensors give humanoid robots the ability to feel, balance, and adapt to enable safe, fluid interaction with the world around them.
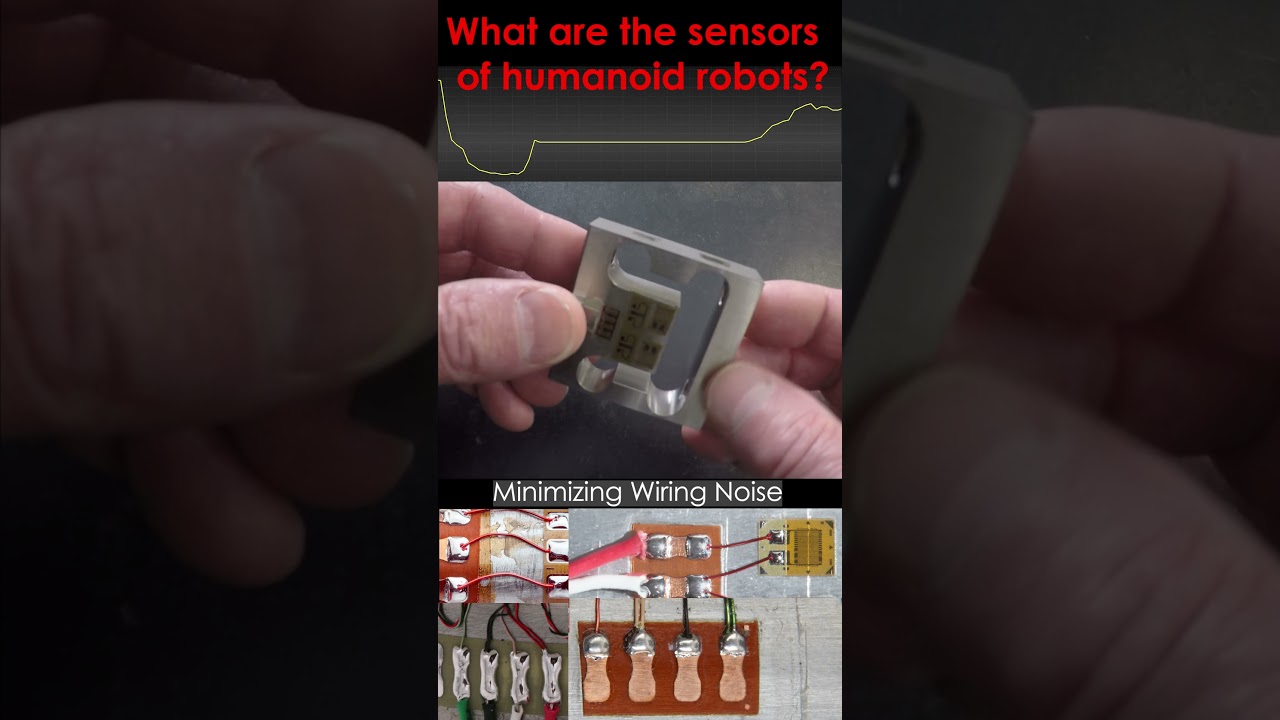
At the heart of many systems are force/torque sensors, often built using foil strain gages in a full Wheatstone bridge configuration. These enable high-resolution detection of load vectors applied at the robot’s joints, limbs, or fingertips that allow for:
🔹 Backdrivability and compliance in robotic limbs
🔹 Tactile feedback during object manipulation
🔹 Force-limited operation for human-robot collaboration
🔹 Real-time collision detection and adaptive path planning
To operate in dynamic environments, these sensors must be compact, low-noise, and robust against temperature drift, electromagnetic interference, and mechanical crosstalk. That’s where miniaturized data acquisition (DAQ) systems come in — often built directly into or near the sensor node to reduce latency and wiring strain.
Our engineering team works closely with OEMs and integrators to tailor force and torque sensing packages that meet the exacting requirements of humanoid robotics — whether it's improving grip feedback in assistive exoskeletons or reducing residual forces in rehabilitation bots.
Humanoid robots are evolving fast. But without the ability to sense force precisely — and to react to it in milliseconds — there's no safe, responsive movement. That’s why strain gage–based sensors aren’t just useful… they’re mission-critical.
In advanced robotics, strain gage–based force and torque sensors are foundational. These sensors give humanoid robots the ability to feel, balance, and adapt to enable safe, fluid interaction with the world around them.
At the heart of many systems are force/torque sensors, often built using foil strain gages in a full Wheatstone bridge configuration. These enable high-resolution detection of load vectors applied at the robot’s joints, limbs, or fingertips that allow for:
🔹 Backdrivability and compliance in robotic limbs
🔹 Tactile feedback during object manipulation
🔹 Force-limited operation for human-robot collaboration
🔹 Real-time collision detection and adaptive path planning
To operate in dynamic environments, these sensors must be compact, low-noise, and robust against temperature drift, electromagnetic interference, and mechanical crosstalk. That’s where miniaturized data acquisition (DAQ) systems come in — often built directly into or near the sensor node to reduce latency and wiring strain.
Our engineering team works closely with OEMs and integrators to tailor force and torque sensing packages that meet the exacting requirements of humanoid robotics — whether it's improving grip feedback in assistive exoskeletons or reducing residual forces in rehabilitation bots.
Humanoid robots are evolving fast. But without the ability to sense force precisely — and to react to it in milliseconds — there's no safe, responsive movement. That’s why strain gage–based sensors aren’t just useful… they’re mission-critical.