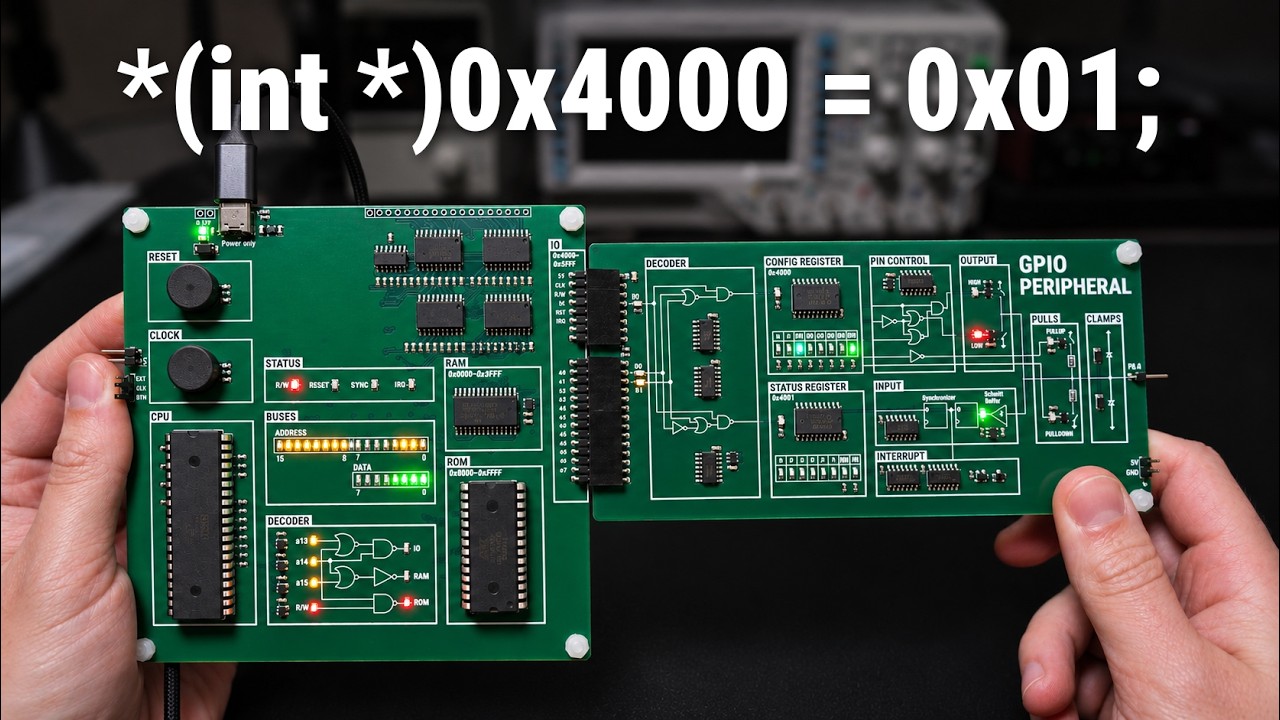
I rebuilt the inside of a microcontroller Artful Bytes 2026-11-09 | Practical Notes on Embedded (starts with a guide to learning embedded by building): artfulbytes.com------I rebuild the inside of a microcontroller from separate chips to show how a CPU talks to the outside world using nothing but memory reads and writes.
My microcontroller crashed. I found out why. Artful Bytes 2026-07-26 | Practical Notes on Embedded (starts with a guide to learning embedded by building): artfulbytes.com------I walk through how to use the clues left inside a crashed microcontroller to trace the failure back to its root cause and fix it.0:00 Overview0:34 Debugger2:08 Registers & memory2:47 Where are we stuck? (PC)4:48 Why? (Status registers)8:27 How did we get here? (Stack)13:17 Frame buffer problem16:15 Stack corruption demo17:24 Dump the error log18:50 The fixCode and parts list: github.com/artfulbytes/why_did_my_microcontroller_crash
I kept coding until an RTOS was inevitable Artful Bytes 2026-05-17 | Practical Notes on Embedded (starts with a guide to learning embedded by building): artfulbytes.com------I start with a simple superloop and keep adding to it until I need an RTOS.Code and parts list: github.com/artfulbytes/i_kept_coding_until_an_rtos_was_inevitable
What Embedded Systems are really about Artful Bytes 2026-03-08 | Practical Notes on Embedded (starts with a guide to learning embedded by building): artfulbytes.com------I put a computer in a book to explain what embedded systems are all about.
How Your Code Really Controls Hardware Artful Bytes 2025-08-31 | Practical Notes on Embedded (starts with a guide to learning embedded by building): artfulbytes.com------I show and explain the mechanism behind how code controls hardware.0:00 Intro2:28 Led4:30 Trimmer6:48 Receipt printer8:25 How it works11:56 Reflection13:25 Laptop
I Shrunk Blinky to 0 Bytes Artful Bytes 2025-03-16 | Practical Notes on Embedded (starts with a guide to learning embedded by building): artfulbytes.com------I take you on a journey from a bloated AI-powered blinky program through C, assembly, and machine code, all the way down to 0 bytes.0:00 Background1:17 AI & Cloud5:34 RTOS6:17 C7:04 Assembly8:42 Code golf9:36 Machine code11:15 0 Bytes
How a Microcontroller starts Artful Bytes 2024-11-03 | Practical Notes on Embedded (starts with a guide to learning embedded by building): artfulbytes.com------We explore the startup of a microcontroller using STM32 as an example. First, we look at the manufacturer's assembly code, then we write it from scratch in C.00:00 Overview01:25 Create a basic project in STM32CubeIDE02:14 Review STM32 startup code (assembly)08:58 Write startup code from scratch (C)10:22 Discard libc, startfiles and default linker script14:27 Startup file16:05 Linker script18:22 Debug18:55 C runtime init (CRT0)23:56 Link with libc (Newlib)24:42 __libc_init_array (constructors)26:49 system_init and _start27:35 Final thoughtsCode: github.com/artfulbytes/how_a_microcontroller_starts_video🌍 Related linksembeddedartistry.com/blog/2019/04/08/a-general-overview-of-what-happens-before-maininterrupt.memfault.com/blog/zero-to-main-1github.com/ataradov/mcu-starter-projects
The End | Embedded System Project Series #28 Artful Bytes 2023-12-18 | In this final video of the series, I summarize my thoughts on the project.0:00 What it was about1:10 Writing from scratch3:16 Fewer motors4:05 Simpler sensors4:56 Better microcontroller6:26 Simpler simulation6:53 What's next?🌍 Related linksProject code - github.com/artfulbytes/nsumo_videoSimulator - github.com/artfulbytes/bots2d🌍 Find me hereGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.#embeddedsystems
Simulation to Real-world Demo | Embedded System Project Series #27 Artful Bytes 2023-11-26 | I finish up the state machine and demonstrate that it works, first in my simulator, Bots2D, and then on my actual robot, Nsumo. This concludes the project.0:00 Overview1:03 Bots2D setup11:50 Simulation 1 (keyboard control)12:39 Integrate app code (controller)15:30 Simulated low-level drivers25:28 Simulation 2 (Nsumo not moving)26:50 Input history31:48 Finish the state machine38:20 Flash is full!42:05 Simulation 3 (It works!)43:30 Real-world demo45:50 Commit47:10 Last words🌍 Related linksProject code - github.com/artfulbytes/nsumo_videoSimulator - github.com/artfulbytes/bots2d🌍 Find me hereGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.#cprogramming #robot #embeddedsystems
How to Code a State Machine | Embedded System Project Series #26 Artful Bytes 2023-10-14 | The application logic of my robot (as many other embedded systems) can be effectively represented as a finite-state machine. In this video, I sketch out the state diagram with PlantUML and prepare the corresponding skeleton code in C.0:00 Overview1:56 Draw diagram with PlantUML12:40 How I will code it13:30 Three previous commits16:09 Files17:25 State machine logic34:48 State wait36:35 State search43:48 State attack49:15 State retreat57:29 State manual59:00 Compile59:40 Flash is full!01:01:00 Commit01:02:05 Last words🌍 Related linksProject code - github.com/artfulbytes/nsumo_videoPlantUML - plantuml.comPlantUML previewer - marketplace.visualstudio.com/items?itemName=Mebrahtom.plantumlpreviewerQuantum Leaps tutorial - youtu.be/EBSxZKjgBXI?feature=sharedWikipedia about State machine - en.wikipedia.org/wiki/Finite-state_machine🌍 Find me hereGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.#cprogramming #robot #embeddedsystems
I made a Robot 2D Simulator with C++ | Embedded System Project Series #25 Artful Bytes 2023-07-29 | I explain how I made a 2D simulator for robotics from scratch in C++. I'm going to use this to help me write the application code for my sumo robot.0:00 Background1:40 Goals2:48 How?4:35 Physics (Box2D)7:00 Graphics (OpenGL)10:10 Software Architecture13:13 Controller code15:00 Main loop16:14 Reflection🌍 Related linksBots2D code - github.com/artfulbytes/bots2dBots2D blog post - artfulbytes.com/bots2d-blogpostGreat Box2D tutorials - iforce2d.net/b2dtutGraphics tutorials - youtube.com/@TheCherno🌍 Find me hereGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.#simulator #2d #robot #embeddedsystems
How to Board Bring-up | Embedded System Project Series #24 Artful Bytes 2023-06-25 | I explain and demonstrate board bring-up by doing a "fake" bring-up of the PCB on my actual robot. To verify the hardware, I run the code I've developed using the development board throughout this video series. While at it, I also fix some issues I discovered in earlier videos.Board bring-up is an important stage of developing an embedded system. The goal is to verify (asap) that the untested hardware works as intended, because if it doesn't, it has to be fixed, so that new boards can be ordered.0:00 What is board bring-up1:45 This video2:41 Power up the board4:39 Flash microcontroller5:07 Board bring-up checklist6:57 Blink LED8:15 UART10:30 Motor driver (TB6612FNG)13:04 ADC16:40 I2C20:55 Bring-up done21:40 Fix 1: assert UART bug!22:49 Fix 2: Build issue24:22 Fix 3: New make rules29:52 Commit changes32:00 Ending words🌍 Related linksProject code - github.com/artfulbytes/nsumo_video🌍 Find me hereGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.#embeddedsystems #cprogramming #microcontroller
I2C driver in C (with VL53L0X sensor) | Embedded System Project Series #23 Artful Bytes 2023-06-13 | My sumobot has five range sensors (VL53L0X) to detect the sumobot enemy. In this video, I write an I2C driver to talk to these sensors and verify the traffic with a logic analyzer. I also add an existing driver on top as well as a software layer (enemy) for a nicer application interface.0:00 intro1:37 I2C driver5:44 I2C init12:00 I2C write19:51 I2C read25:54 Test function29:00 Logic analyzer31:18 Doesn't work...34:05 Yes works!38:18 Commit 140:05 VL53L0X driver43:21 Test VL53L0X47:12 Interrupt flank BUG!48:33 Commit 250:00 Detect enemy1:00:43 Commit 31:01:24 Video series code summary🌍 Related linksProject code - github.com/artfulbytes/nsumo_videoVL53L0X blog post - artfulbytes.com/vl53l0x-postWhat is I2C - youtube.com/watch?v=jFtr0Ha5f-cI2C in a Nutshell - interrupt.memfault.com/blog/i2c-in-a-nutshell?mc_cid=65ee99e52d&mc_eid=[f93c21bf5e]🌍 Find me hereGitHub - github.com/artfulbytesInstagram - instagram.com/artfulbytescomWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.#embeddedsystems #cprogramming #microcontroller
ADC driver with DMA in C | Embedded System Project Series #22 Artful Bytes 2023-05-24 | My sumobot has four line sensors to detect the white border that surrounds the platform. In this video, I write an ADC driver to sample the values from these sensors. To reduce CPU load, I employ a sequential sampling strategy where the ADC peripheral samples and writes all channel values to memory via DMA before interrupting the CPU. Finally, I add additional software abstractions to turn the raw voltage values into actual line positions. 0:00 Line sensors1:11 Code overview2:12 ADC driver4:40 Assign ADC pins8:26 My ADC strategy18:10 Interrupt19:18 Get values21:43 Test ADC driver23:00 Fix bugs24:10 It works!25:00 Commit 127:25 QRE1113 driver32:15 Works!32:45 Commit 233:41 Voltage to Line position37:58 Test with real sensor40:05 Commit 3#embeddedsystems #cprogramming #microcontroller 🌍 Related linksgithub.com/artfulbytes/nsumo_video🌍 Find me hereGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Motor Control with PWM in C | Embedded System Project Series #21 Artful Bytes 2023-04-18 | I write C code to control four brushed DC motors using two motor drivers (TB6612FNG) and a microcontroller (MSP430). Each motor driver requires two control inputs and one pulse-width modulation (PWM) input. I create three abstraction layers: a PWM driver at the bottom, a motor driver in the middle, and a simplified drive interface at the top. 21 videos in and something is finally moving.0:00 What2:19 Motor circuit2:45 PWM driver26:00 Multimeter/Oscilloscope (DEMO)27:48 Commit 129:15 Motor driver36:30 Motor spinning (DEMO)37:30 Commit 239:30 Drive interface50:27 Remote control (DEMO)51:30 Commit 352:00 Assert stop motors55:42 Assert triggers! (DEMO)55:56 Commit 456:38 Last words#embeddedsystems #cprogramming #microcontroller 🌍 Related linksgithub.com/artfulbytes/nsumo_video🌍 Find me hereGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
NEC Protocol Driver (Infrared remote) | Embedded System Project Series #20 Artful Bytes 2023-04-05 | I develop a simple driver to decode the signal between an IR remote and my robot. The square-like signal follows the NEC protocol, which I decode by detecting the edges through GPIO interrupts, and measure the time between them using the microcontroller's timer peripheral.0:00 Intro1:30 New project4:00 Driver interface (ir_remote.h)5:55 Timer peripheral15:27 GPIO interrupt16:45 NEC protocol18:22 My first solution19:00 A simpler solution25:00 Ring buffer27:30 Test it29:09 Handle "held" button33:19 Move to main project34:00 Trace button press37:10 It works!38:00 Commit#embeddedsystems #cprogramming #microcontroller 🌍 Related linksgithub.com/artfulbytes/nsumo_videotechdocs.altium.com/display/FPGA/NEC+Infrared+Transmission+Protocol🌍 Find me hereGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Printf on a Microcontroller | Embedded System Project Series #19 Artful Bytes 2023-03-14 | I add a printf implementation suitable for microcontrollers so that I can print formatted strings to the terminal. Underneath, it calls the UART driver I implemented in the last video. I further wrap the printf function in a TRACE macro to prefix every trace with filename and line number. Finally, I add trace to my assert function, but only trace the program counter (PC) to save space and show how to get the corresponding file+line with addr2line.0:00 What and Why3:28 Add mpaland/printf6:52 Implement _putchar9:20 Call printf11:40 TRACE macro17:13 Verify TRACE19:10 Avoid format and cppcheck22:20 Commit22:58 Fix mistake 123:25 Fix mistake 224:00 Add trace to ASSERT28:30 Program counter assembly29:53 UART polling in ASSERT32:20 Fix mistakes34:05 addr2line36:25 Commit37:20 Possible improvements#embeddedsystems #cprogramming #microcontroller 🌍 Related linksgithub.com/artfulbytes/nsumo_videointerrupt.memfault.com/blog/asserts-in-embedded-systemsgithub.com/mpaland/printf🌍 Find me hereGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Write a UART driver (Polling and Interrupt) | Embedded System Project Series #18 Artful Bytes 2023-02-26 | I explain what UART is and show how I use it to print text from my microcontroller to my desktop computer. I first implement a UART driver based on polling and then improve on it by making it interrupt-driven with a ring buffer. This driver will serve as the foundation for when I implement log tracing (printf) in my next video.0:00 Goal0:50 Outline2:30 What is UART?4:25 RS2325:43 Why UART?6:48 USB-to-UART bridge8:42 Implement polling driver10:45 Start, data, parity, stop bits11:50 New project15:40 Initialize UART peripheral20:15 Compile25:46 UART send function27:35 Print to terminal30:15 Interrupt + Ring buffer36:00 Implement ring buffer40:40 Implement interrupt driver49:00 Verify interrupt driver51:40 Move to robot project53:15 Commit#embeddedsystems #cprogramming #microcontroller 🌍 Links related to this videocode - github.com/artfulbytes/nsumo_videocircular buffer - en.wikipedia.org/wiki/Circular_buffercircular buffer - embeddedartistry.com/blog/2017/05/17/creating-a-circular-buffer-in-c-and-cdatasheet - ti.com/lit/ug/slau144k/slau144k.pdf🌍 Find me hereGitHub - github.com/artfulbytesInstagram - instagram.com/artfulbytescomWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Microcontroller Interrupts | Embedded System Project Series #17 Artful Bytes 2023-02-18 | I explain how microcontroller interrupts work by mixing theory with a code example. For fun, I let ChatGPT generate my code example. I also add some functions in my project that lets me add new GPIO interrupts more easily. Finally, I bump the clock speed of my microcontroller from 1 MHz to 16 MHz, not because I need to, but because I can.0:00 Outline3:12 Why polling is bad9:40 How does interrupts work?20:30 Interrupt advantages21:38 ChatGPT code example25:56 Interrupt vector table28:47 Disassembly of ISR30:36 GPIO interrupts in my project38:25 PORT1 and PORT2 ISRs42:30 Test my code44:25 Fix my code46:43 Commit 147:27 Increase clock speed53:25 Commit 2#embeddedsystems #cprogramming #microcontroller 🌍 Links related to this videogithub.com/artfulbytes/nsumo_video🌍 Find me hereGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
How Microcontroller Memory Works | Embedded System Project Series #16 Artful Bytes 2023-02-04 | Practical Notes on Embedded (starts with a guide to learning embedded by building): artfulbytes.com------I explain how microcontroller memory works with a code example. I use my IDE's memory browser to see where different variables end up in memory, and I demonstrate two command line tools to track how much flash memory my code occupies. Overall, knowing how memory works is important because microcontrollers have a limited amount of it, and if we are not mindful of how we write our code, we may run out of it.0:00 Overview1:30 Flash and RAM3:22 From source code to memory7:12 Code example8:07 Different variables12:20 Program code13:13 Linker script14:55 Memory browser and Map file24:22 Surprising flash usage27:30 Tool 1: Total flash usage31:38 Tool 2: readelf33:53 git commit33:15 Last advice#embeddedsystems #cprogramming #microcontroller Code: 🌍 Links related to this videointerrupt.memfault.com/blog/zero-to-main-1embeddedartistry.com/blog/2019/04/08/a-general-overview-of-what-happens-before-maingithub.com/artfulbytes/nsumo_video🌍 Find me hereGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
My Small Test Functions | Embedded System Project Series #15 Artful Bytes 2023-01-22 | During development, I tend to add scratch functions to test a particular part of the code. In this video, I try to handle these functions in a less ugly way.0:00 Background1:20 Move the test functions2:50 Add TEST argument to make5:15 Fix errors5:45 Suppress unused functions7:02 Ugly workaround7:50 Build all functions in CI9:53 git commit11:00 Last words#embeddedsystems #cprogramming Code: github.com/artfulbytes/nsumo_video⌨️ My development environmentartfulbytes.com/devenv🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Assert on a Microcontroller | Embedded System Project Series #14 Artful Bytes 2023-01-16 | I create an assert implementation for my microcontroller. It stops the motors, logs to a terminal, triggers a breakpoint, and blinks an LED.0:00 Assert1:00 This video1:20 My implementation2:26 Custom assert function3:53 Software breakpoint4:55 With TI compiler6:05 With GCC compiler7:08 Add breakpoint to assert function9:05 LED driver11:27 Two new IO functions13:47 Test the LED driver14:35 Test asserts15:37 Recursive assert problem!17:09 Busy wait macro18:05 Commit 119:00 Static assert20:55 Commit 221:30 Replace todos (I forgot!)22:20 Last words#embeddedsystems #cprogramming #electronics Code: github.com/artfulbytes/nsumo_video🌍 Useful linksinterrupt.memfault.com/blog/asserts-in-embedded-systems⌨️ My development environmentartfulbytes.com/devenv🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Handling multiple Hardware Versions | Embedded System Project Series #13 Artful Bytes 2023-01-03 | I show how I handle two different hardware targets (robot and development board) sharing the same software. First at compile time and then at runtime.0:00 Intro0:42 Overview1:32 Add argument to make (compile time)3:50 Some exceptions4:20 Commit 14:52 Detect hardware at runtime6:18 Modifying my PCB8:00 Write code to detect pullup9:00 Test Robot9:43 Test Launchpad10:02 Separate folders10:30 Commit 210:47 Fix typos from last video11:18 Outro#embeddedsystems #cprogramming #electronics 🌍 Useful linksbeningo.com/5-tips-for-versioning-embedded-systemsembeddedartistry.com/fieldatlas/versioning-pcbs github.com/artfulbytes/nsumo_video⌨️ My development environmentartfulbytes.com/devenv🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
How I program GPIOs in C | Embedded System Project Series #12 Artful Bytes 2022-12-18 | I program the I/O-pins on my robot (and development board) according to the pin assignment in my schematic. Writing to registers is cumbersome, so to make things easier, I implement a code abstraction in C that lets me configure and initialize all pins in a single place.The git repository:github.com/artfulbytes/nsumo_video0:00 Recap0:44 Introduction1:57 Why start here?3:18 Setup4:00 Pin Mapping5:40 How are IO pins configured?7:25 Memory-mapped registers8:56 Blinky example9:42 Defining the interface (io.h)10:15 Select register11:32 Direction register11:59 Resistor register (pullup/pulldown)13:22 Input register13:57 First commit14:39 How to implement?15:39 Bitwise operation (code trick!)17:29 Array indexing (code trick!)18:52 Implementation (io.c)19:53 Testing the code22:38 Second commit22:55 Initialize all pins28:27 Third commit28:44 Last words#embeddedsystems #gpio #cprogramming ⌨️ My development environmentartfulbytes.com/devenv🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Documentation and Clang format (+2 bugs) | Embedded System Project Series #11 Artful Bytes 2022-11-22 | I thought I was ready to start writing code, but I had a few more things to discuss first. I talk about the documentation (README.md), coding guidelines, code formatting of the project. I also solve two bugs I ran into while writing code for the coming videos. The first bug was that the Makefile didn't track the header files, and the second one that cppcheck took a long time to execute.The git repository:github.com/artfulbytes/nsumo_video0:00 Intro0:24 Documentation (README.md)0:59 Coding guidelines1:46 Ignoring files (bear)2:01 Commit 1/42:23 Code formatting with clang-format3:21 Add formatting rule to Makefile4:00 Add formatting step to CI system4:47 Commit 2/45:28 Bug 1: Headers not tracked by Make7:02 Commit 3/47:24 Bug 2: cppcheck slow!9:00 Commit 4/4 #embeddedsystems #documentation #clang-format⌨️ My development environmentartfulbytes.com/devenv🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Simple CI/CD with GitHub Actions and Docker (Compile+Analysis) | Embedded System Project Series #10 Artful Bytes 2022-10-09 | I set up a simple continuous integration (CI) / continuous delivery (CD) pipeline using GitHub actions. Its job is to automatically build and analyse my code every time I push a new commit to GitHub. I create a docker image to hold the cross-toolchain (msp430-gcc) that I'm using to build the code for my target. the msp430 microcontroller. With this solution, the toolchain is always available in the GitHub action, and I don't have to worry about it breaking at some later point.The git repository:github.com/artfulbytes/nsumo_video0:00 Overview2:37 Create a Docker Image7:54 Create a GitHub Action9:37 First fail (indentation)10:00 Branch rule10:55 Second fail (path)11:17 Modify Makefile12:20 Test branch rule12:39 Pull request13:13 Third fail (config)14:20 Success!14:50 Possible improvement15:15 Last words⌨️ My development environmentartfulbytes.com/devenv🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Static Analysis for C/C+ with cppcheck (+Makefile) | Embedded System Project Series #9 Artful Bytes 2022-10-02 | As a programmer, I make mistakes, the compiler catches some, but far from all, and to catch more I use a static analyser. In this video, I demonstrate cppcheck, which is a static analyser for C/C++. I show how to enable and suppress errors, and create a Makefile-rule that lets me run "make cppcheck" from the command-line to check my entire project.Code: github.com/artfulbytes/nsumo_videoExample 1:cppcheck --quiet --enable=all --error-exitcode=1 main.c file1.c src/ -I include/Example 2 (suppress specific error):cppcheck --quiet --enable=all --error-exitcode=1 --suppress=unusedFunction:main.c:10:00 cppcheck0:36 Install and Run1:06 Enable more errors1:50 Suppress errors2:43 Multiple files3:03 Makefile4:24 Git commit and last words🌍 Linkscppcheck.sourceforge.io/manual.pdf⌨️ My development environmentartfulbytes.com/devenv🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
How I version control with git (Best Practices) | Embedded System Project Series #8 Artful Bytes 2022-09-24 | I explain how I'm going to use git in this project series including how I write good commit messages. I initialize the repository and make the first two commits.The repository: github.com/artfulbytes/nsumo_video0:00 Intro0:55 Why git?3:32 Git in this project4:39 My 3 commit rules5:36 Write a good commit message8:08 First commit11:07 Bonus commit13:10 Last words🌍 Links mentionedconventionalcommits.org⌨️ My development environmentartfulbytes.com/devenv🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
The BEST Project Structure for C/C++/MCU | Embedded System Project Series #7 Artful Bytes 2022-09-03 | In this video, I talk about how I'm going to organize the files of the project and I present the following structure:build/docs/src/ app/ common/ drivers/ test/ main.ctools/.clang-format.gitignoreLICENSEMakefileREADME.mdIs this the best project structure? Well, take a look at the video for my opinion :)0:00 What's the best structure?1:33 Ex 1: The Pitchfork Layout2:13 Ex 2: Canonical Project Structure2:45 My project structure7:35 Naming conventions7:57 Last words🌍 Links mentionedThe Pitchfork Layout - api.csswg.org/bikeshed/?force=1&url=raw.githubusercontent.com/vector-of-bool/pitchfork/develop/data/spec.bsCanonical Project Structure - open-std.org/jtc1/sc22/wg21/docs/papers/2018/p1204r0.htmlcliutils.gitlab.io/modern-cmake/chapters/basics/structure.htmlgithub.com/embeddedartistry/project-skeleton⌨️ My development environmentartfulbytes.com/devenv🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
How to Create a Software Architecture | Embedded System Project Series #6 Artful Bytes 2022-08-13 | I talk about the software architecture of my sumobot and show a block diagram that will keep us oriented in the coming programming videos. I also explain why you should architect your code and some things to consider when you do. Overall, a tiny dip into an otherwise ocean-deep topic.0:00 Intro1:08 Disclaimer1:24 Outline2:37 Why organize software?6:04 Sumobot Software Architecture7:36 Application layer10:25 Drivers layer13:25 A few comments14:13 Why this architecture?15:05 Books15:15 Principles & Patterns15:40 Over-theorizing16:18 How to think?17:20 Hardware diagram19:08 Pattern & Principles I followed22:21 Remember the Whys24:04 Last wordsDiagram: artfulbytes.com/sw-arch-youtube🌍 Links mentioned in this videoembeddedartistry.com/blog/2019/07/12/embedded-systems-architecture-resourcesgithub.com/mpaland/printf⌨️ My development environmentartfulbytes.com/devenv🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Microcontroller Programming without IDE (Makefile + Toolchain) | Embedded System Project Series #5 Artful Bytes 2022-07-20 | There are two common ways to set up a development environment for a microcontroller (embedded) project:IDE - Use the integrated development environment (IDE) provided by the vendor.CLI - Use the toolchain from the command-line (CLI), build with make (Makefile), and use your code editor of choice.In the last video, I focused on the first approach and set up an IDE, Code Composer Studio (CCStudio). In this video, I focus on the second approach. I talk about toolchains, the advantages of building from the command-line, and show how to install a GCC-based toolchain and use it to compile the same blink LED project (MSP430) as in the last video. Finally, I create a Makefile from scratch to make building easier.0:00 Intro1:00 Video outline2:18 Why build from command-line?4:10 Toolchains06:48 Download GCC-based toolchain09:15 Build blink project with gcc15:35 Compiler options20:30 Add more source files24:10 Vim editor25:01 Makefile intro26:35 Create new Makefile28:41 Add variables30:07 More compiler flags33:31 Separate compilation and linking35:54 Pattern rule36:46 Automatic variables37:52 Put build files in separate directory40:30 Substitution reference and patsubst43:01 Phony targets all and clean44:37 Flash microcontroller using make 47:10 Makefile finished47:51 What about CMake?49:01 Recap49:38 General advice🖥️ Codegist.github.com/niklasab/78b110d5a8bdb9f48ca71d0cac76ae42🌍 Links mentioned in this videointerrupt.memfault.com/blog/best-and-worst-gcc-clang-compiler-flagsartfulbytes.com/makefile-microcontroller⌨️ My development environmentartfulbytes.com/devenv🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻 About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Install an IDE and Blink an LED (Code Composer Studio + MSP430) | Embedded System Project Series #4 Artful Bytes 2022-07-06 | There are two common ways to set up a development environment for a microcontroller (embedded) project:IDE - Use the integrated development environment (IDE) provided by the vendor.CLI - Use the toolchain from the command-line (CLI), build with make (Makefile), and use your code editor of choice.The first is the most straightforward way and is what I demonstrate in this video. I show how to set up Code Composer Studio (CCStudio), the IDE that TI provides for their microcontrollers. I install it on Linux and get the Blink LED example program to run on the evaluation board (MSP430 Launchpad). In the next video, I will demonstrate the second way, which is the one I prefer.0:00 Intro and Overview1:08 Why I use the Evaluation board3:04 Compile code for a Microcontroller4:00 CCStudio intro4:20 Install CCStudio4:50 Why Linux?6:10 Continue installation10:28 Blink LED15:15 Outro⌨️ My development environmentartfulbytes.com/devenv🖥️ Hardware and Softwaregithub.com/artfulbytes/nsumo_softwaregithub.com/artfulbytes/nsumo_hardwareNote, going over the project a second time, the code might end up slightly different (better).🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
PCB Design Walkthrough Sumo Robot | Embedded System Project Series #3 Artful Bytes 2022-06-30 | In the last video, I started going over the hardware of the sumobot by talking about its parts. In this video, I continue by explaining the printed circuit board (PCB) I made to connect them. It's a 2-layer PCB with a microcontroller (MSP430G2553IPW28), two regulators (AMS1117-3.3 and MP2359-5V), two motor drivers (TB6612FNG), and an IR receiver (TSOP382). I designed it in KiCad, an open-source software suite for designing PCBs.0:00 Intro0:53 Why PCBs?1:50 My design3:13 Schematic3:48 Power input4:30 Regulators6:45 Microcontroller8:24 Range sensors9:02 Line sensors9:45 IR receiver10:10 Unused pins10:35 How I program it11:08 Motor drivers11:57 Outro 🖥️ Hardware and Softwaregithub.com/artfulbytes/nsumo_softwaregithub.com/artfulbytes/nsumo_hardwareNote, going over the project a second time, the code might end up slightly different (better).🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Picking the Parts for a Small Robot | Embedded System Project Series #2 Artful Bytes 2022-06-23 | Programming an embedded system is basically about controlling a piece of hardware, and it's essential to understand that hardware to program it. So in this video, I start talking about the hardware (sumobot) I'm going to be programming in the coming videos. I show a hardware block diagram and discuss the parts and why I picked them, including the motors, sensors, battery, and microcontroller. I also explain why I didn't use an Arduino, and why I don't think you should if you want to learn embedded systems development.📋 HW block diagram - artfulbytes.com/static/c90de6b04f8aa977bb8d2a026a13dd9e/16038/sysdiag.jpg⚙️ The partsMotor driver (out of stock) - https://www.digikey.se/en/products/detail/toshiba-semiconductor-and-storage/TB6612FNGC8EL/1730134Motor - jsumo.com/core-dc-motor-6v-400-rpmRange sensor - st.com/en/imaging-and-photonics-solutions/vl53l0x.htmlLine sensor (analog version) - sparkfun.com/products/9453Battery - https://www.amazon.se/Makerfire-LiPo-batteri-intelligent-Quadcopter-reservdelar/dp/B07M9T66WVMicrocontroller -ti.com/tool/MSP-EXP430G2EThttps://www.digikey.se/sv/products/detail/texas-instruments/MSP430G2553IPW28R/2638887Note, I 've already built this project, so the code and hardware design are available on GitHubgithub.com/artfulbytes/nsumo_softwaregithub.com/artfulbytes/nsumo_hardwareOf course, going over it a second time, the code might end up slightly different (better).0:00 Intro1:12 Hardware block diagram1:35 Motors11:00 Motor drivers13:39 Range sensors18:42 Line sensors19:18 IR receiver19:50 Battery21:47 Why not Arduino?24:07 Microcontroller29:47 Recap🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
Intro and Overview | Embedded System Project Series #1 Artful Bytes 2022-06-17 | Practical Notes on Embedded (starts with a guide to learning embedded by building): artfulbytes.com------I am introducing a new video series that will focus on programming a sumobot (embedded system) from scratch in the programming language C, including drivers for common peripherals like GPIO, UART, ADC, I2C, Timers, and more. With this series, I aim to show what embedded systems programming might look like in the context of a project, which is different from the typical one-off tutorial because you have to consider more aspects when writing the code.Note, I 've already built this project, so the code and hardware design is available on GitHubgithub.com/artfulbytes/nsumo_softwaregithub.com/artfulbytes/nsumo_hardwareOf course, going over it a second time, the code might end up looking slightly different (better).0:00 Intro0:25 About the sumobot project1:23 Why is this a good project? 1:58 Focus of this series2:49 Overall structure3:56 Last words🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.
A Channel about Embedded Systems Artful Bytes 2022-06-11 | A short video about what this channel will be about, why I started it, and who I am.0:00 Welcome0:10 The content I will create0:38 Embedded Systems1:00 Why start this channel?1:32 Who am I?2:00 The first project 🌍 LinksGitHub - github.com/artfulbytesWebsite - artfulbytes.com👨💻About meHi and welcome. I'm Niklas, an embedded systems engineer from Sweden. On this channel, I make practical videos about embedded systems or, in general terms, about building and programming hardware.