Uploaded March 2025 | Updated September 2026, 3 weeks ago
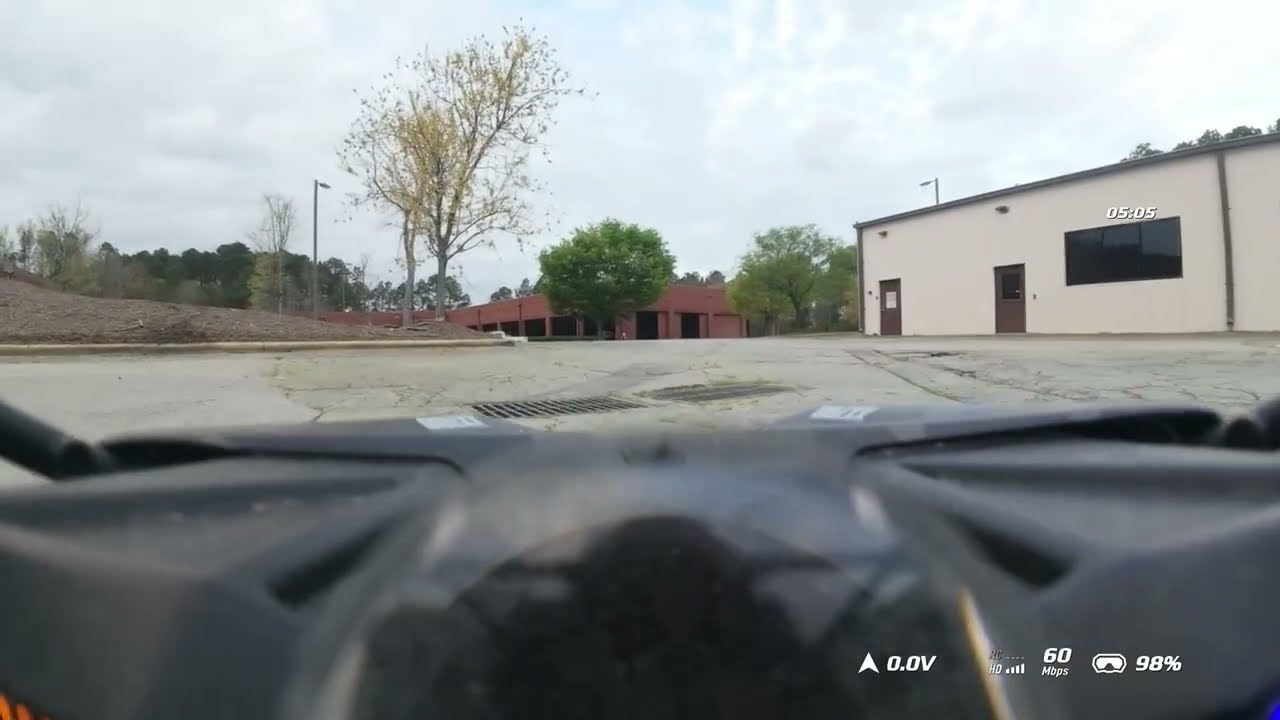
This is the new release of the HEQ gimbal with O4 Pro compatibility out of the box. I have it mounted using the provided rubber standoffs and it's further held down with small zipties through the standoffs. Still dealing with typical jitter issues I can hopefully fix over time like I did the other 2.
Test 1: W/counterweight on the back of gimbal using ~2 quarters. Needed magnets to force it to initialize. Good stabilization of Yaw but some jitter in Pitch.
Test 2: Removed counterweight on back of gimbal. Small counterweight of hot glue on back of Pitch axis. Pitch stabilization looks good, but Yaw looks bad.
Test 3 Next.. Added rear counterweight of 2 quarters again, added a bit more Pitch axis counterweight, but will still need the magnet trick to initialize the gimbal. Will try adding even MORE counterweight on the rear to see if that actually makes a difference in the initializing process.
When it came to first fixing that initializing problem I'm not real sure what happened. I may have confused it with the rear counterweight but I really don't see a way around this for it to stabilize properly. I already tried all kinds of firmware reflashes and settings changes as well as calibrating it all over and that didn't work until I removed the counterweights. My other 2 gimbals don't work right without the counterweights so I think I'll just have to make sure I always bring some magnets with me when using this thing.
This is the new release of the HEQ gimbal with O4 Pro compatibility out of the box. I have it mounted using the provided rubber standoffs and it's further held down with small zipties through the standoffs. Still dealing with typical jitter issues I can hopefully fix over time like I did the other 2.
Test 1: W/counterweight on the back of gimbal using ~2 quarters. Needed magnets to force it to initialize. Good stabilization of Yaw but some jitter in Pitch.
Test 2: Removed counterweight on back of gimbal. Small counterweight of hot glue on back of Pitch axis. Pitch stabilization looks good, but Yaw looks bad.
Test 3 Next.. Added rear counterweight of 2 quarters again, added a bit more Pitch axis counterweight, but will still need the magnet trick to initialize the gimbal. Will try adding even MORE counterweight on the rear to see if that actually makes a difference in the initializing process.
When it came to first fixing that initializing problem I'm not real sure what happened. I may have confused it with the rear counterweight but I really don't see a way around this for it to stabilize properly. I already tried all kinds of firmware reflashes and settings changes as well as calibrating it all over and that didn't work until I removed the counterweights. My other 2 gimbals don't work right without the counterweights so I think I'll just have to make sure I always bring some magnets with me when using this thing.