Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Thu AM Pod J.2
Authors: Chuang, Tzu-Kuan; Lin, Ni-Ching; Chen, Jih Shi; Hung, Chen-Hao; Huang, Yi-Wei; Teng, Chunchih; Huang, Haikun; Yu, Lap-Fai; Giarrè, Laura; Wang, Hsueh-Cheng
Title: Deep Trail-Following Robotic Guide Dog in Pedestrian Environments for People Who Are Blind and Visually Impaired - Learning from Virtual and Real Worlds
Abstract:
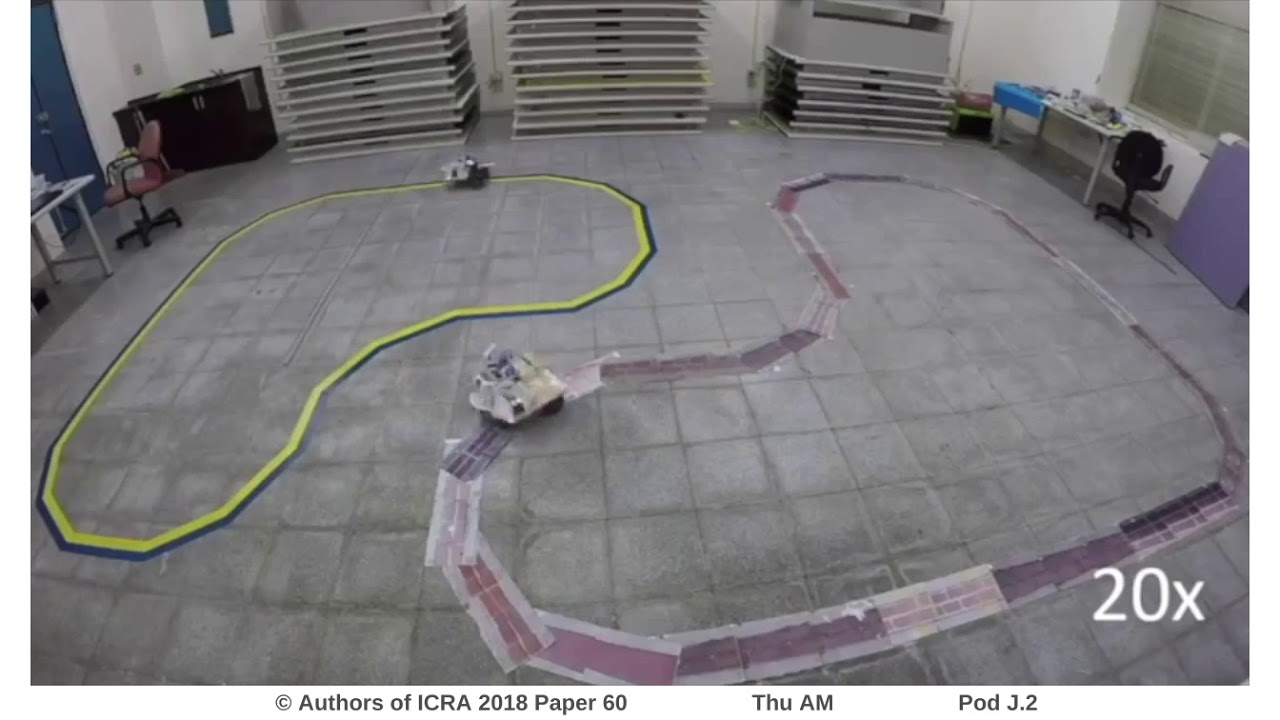
Abstract Navigation in pedestrian environments is critical to enabling independent mobility for the blind and visually impaired (BVI) in their daily lives. White canes have been commonly used to obtain contact feedback for following walls, curbs, or man-made trails, whereas guide dogs can assist in avoiding physical contact with obstacles or other pedestrians. However, the infrastructures of tactile trails or guide dogs are expensive to maintain. Inspired by the autonomous lane following of self-driving cars, we wished to combine the capabilities of existing navigation solutions for BVI users. We proposed an autonomous, trail-following robotic guide dog that would be robust to variances of background textures, illuminations, and interclass trail variations. A deep convolutional neural network (CNN) is trained from both the virtual and real-world environments. Our work included major contributions: 1) conducting experiments to verify that the performance of our models trained in virtual worlds was comparable to that of models trained in the real world; 2) conducting user studies with 10 blind users to verify that the proposed robotic guide dog could effectively assist them in reliably following man-made trails.
ICRA 2018 Spotlight Video
Interactive Session Thu AM Pod J.2
Authors: Chuang, Tzu-Kuan; Lin, Ni-Ching; Chen, Jih Shi; Hung, Chen-Hao; Huang, Yi-Wei; Teng, Chunchih; Huang, Haikun; Yu, Lap-Fai; Giarrè, Laura; Wang, Hsueh-Cheng
Title: Deep Trail-Following Robotic Guide Dog in Pedestrian Environments for People Who Are Blind and Visually Impaired - Learning from Virtual and Real Worlds
Abstract:
Abstract Navigation in pedestrian environments is critical to enabling independent mobility for the blind and visually impaired (BVI) in their daily lives. White canes have been commonly used to obtain contact feedback for following walls, curbs, or man-made trails, whereas guide dogs can assist in avoiding physical contact with obstacles or other pedestrians. However, the infrastructures of tactile trails or guide dogs are expensive to maintain. Inspired by the autonomous lane following of self-driving cars, we wished to combine the capabilities of existing navigation solutions for BVI users. We proposed an autonomous, trail-following robotic guide dog that would be robust to variances of background textures, illuminations, and interclass trail variations. A deep convolutional neural network (CNN) is trained from both the virtual and real-world environments. Our work included major contributions: 1) conducting experiments to verify that the performance of our models trained in virtual worlds was comparable to that of models trained in the real world; 2) conducting user studies with 10 blind users to verify that the proposed robotic guide dog could effectively assist them in reliably following man-made trails.