Uploaded December 2010 | Updated September 2026, 3 hours ago
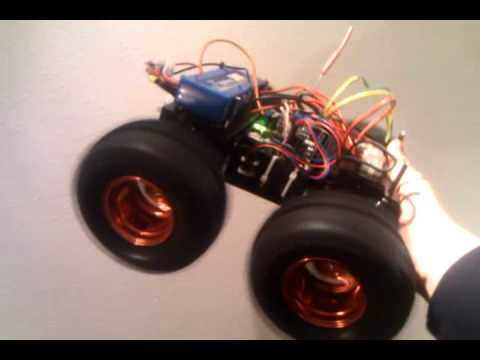
We would like the Dagu 4WD with the WildThumper Arduino controller board to be able to self balance. This is a first attempt at changing the direction and speed of the wheels in proportion to the inclination angle. The code uses input from an accelerometer and a gyro. this is very preliminary and as you can see there is (a) delay in reacting to the incline angle and (b) there is a lot of calibration to be done before we let the code take control of the car.
The code does some predictive filtering (kalman) already using 2 sources but it is a rough sketch and still needs finetuning. we are not sure that it will be able to self balance because the gear reduction we use here is 34/1 which is great for outdoor speed but not for fine control at low speed.
We used a big LiPo battery 5000mah and Accelerometer from Kondo (RAS2) and gyro from Kondo and we dont have their parameters so until we get a CH-Robotics or sparkfun IMU, we'll have to do the calibration by trial and error.
We would like the Dagu 4WD with the WildThumper Arduino controller board to be able to self balance. This is a first attempt at changing the direction and speed of the wheels in proportion to the inclination angle. The code uses input from an accelerometer and a gyro. this is very preliminary and as you can see there is (a) delay in reacting to the incline angle and (b) there is a lot of calibration to be done before we let the code take control of the car.
The code does some predictive filtering (kalman) already using 2 sources but it is a rough sketch and still needs finetuning. we are not sure that it will be able to self balance because the gear reduction we use here is 34/1 which is great for outdoor speed but not for fine control at low speed.
We used a big LiPo battery 5000mah and Accelerometer from Kondo (RAS2) and gyro from Kondo and we dont have their parameters so until we get a CH-Robotics or sparkfun IMU, we'll have to do the calibration by trial and error.