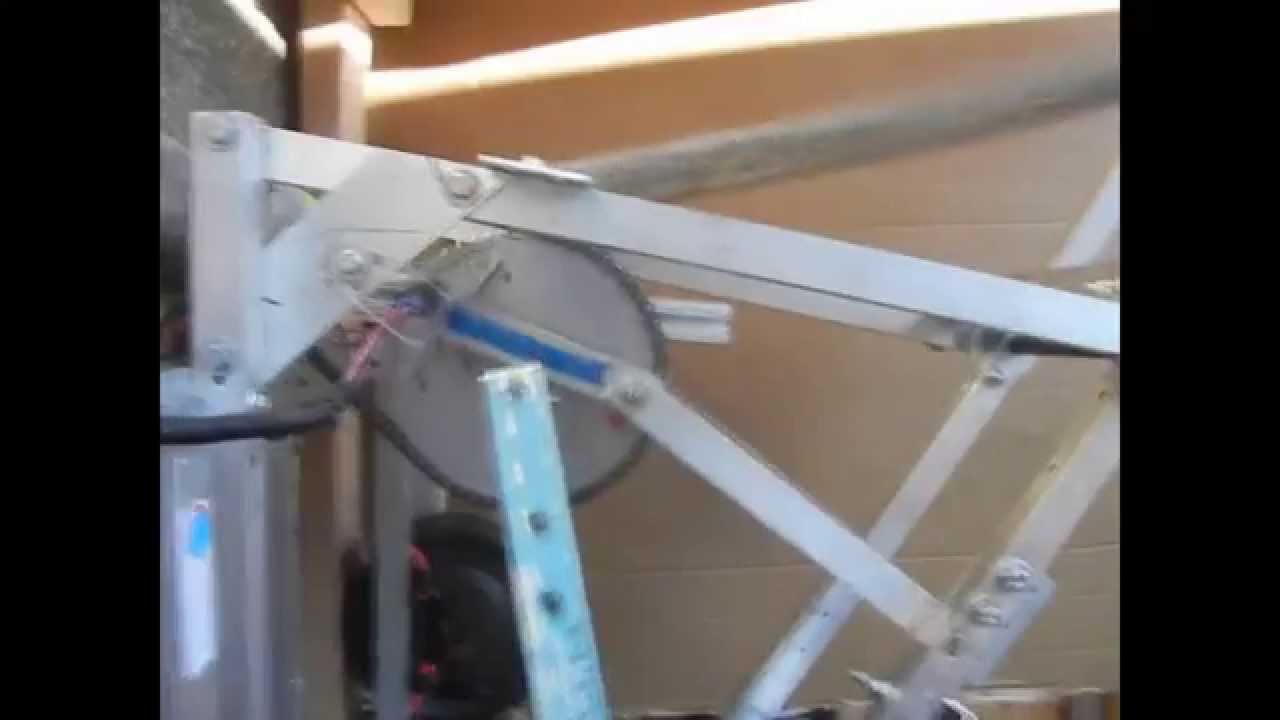
Choo Choo Quick Release Explained Steve Amorosi 2015-08-17 | This is an instructional video on how the choo choo quick release mechanism works. This is on behalf of FRC Team 4030, NullPointerException, from Ingraham High School, Seattle, WA. The team did not use this mechanism in 2014 (Aerial Assist) but started working on it (ran out of time, imagine that!). The mechanism was completed it in the summer of 2015, to get a better understanding of how it works for future uses.
MAKE3 Robot Arm complete design Steve Amorosi 2023-06-09 | This video goes with the GitHub repository github.com/sramorosi/MAKE3-Arm which contains the complete design for the MAKE3 Robot Arm, controller, and the code to control the arm (both remote control and programmable). This is intended to be a low-cost (less than US $ 250), do it yourself (mostly 3D printed or made with common shop tools), remote controlled robot arm. It can be used for stacking/unstacking things for fun, delivering things without getting too close, as a learning tool whereby you learn by making, and much more.
MAKE3 5Cone 700MMPS Steve Amorosi 2022-10-08 | Here is a video of my Make3 robot arm, programmed (automated) to place 5 FTC POWERPLAY cones on the medium junction, from the 5 cone stack. This is not what the team is designing for competition, but it is presented as an example of what is possible with a servo-driven robot arm. The Make3 has 6 servos and is driven by an Arduino Leonardo. The arm fits in an FTC 18 inch^3 sizing box. The Arduino program is designed to move the claw at 700 mm per second, which results in about 23 seconds for the 5 cone cycle. I have not tried to push it faster. The code is at github.com/sramorosi/Arduino , in the MAKE3 folder. This is development code, it will change, and has little testing.There is a manual control mode for the arm, using the mini robot arm (light blue thing on the floor with cable leading to the arm). The automated movement of the arm is faster than what a human can do controlling the arm in the manual (teleoperated) mode, because automated has consistent precision and executes many steps quickly. This Make3 arm does not have any sensors, and it took some trial and error to position the arm on the floor so that the movements consistently work. Any robot for POWERPLAY will need some sensors to position itself for consistent movements.
Servo Actuated robot arm with Compliant Claw (SACC), Make 2 Steve Amorosi 2022-03-15 | Build documents for the SACC Make2 arm, and Input Arm can be found at Thingiverse:SACC Robot Arm, Make 2: thingiverse.com/thing:5318858Input Arm, Make 2: thingiverse.com/thing:5318293
Displaying Hundredth Seconds Steve Amorosi 2021-09-24 | Many experiments involve measuring time in steps that are less than what the human eye can see (about 30 frames per second - FPS). Luckily, there are many low cost video cameras that can capture 240 FPS or greater. The GoPro is one such camera. This video shows some of my efforts to add a stopwatch to a high FPS video, to record distance vs. time at 1/100 of a second. I thought that I could find a high FPS video to use, but I didn’t have much luck (and didn’t try very hard). I tried recording stopwatches on Android phones and on actual sports stopwatches, but they don’t display every 1/100 of a second. This is a display issue for those digital devices.I ended up recording a DC motor spinning at about 600 RPM with 1/10 marks around the outside to be able to capture 1/100 of a second. This worked well with the GoPro. Note: my DC motor control setup could not quite hold 600 RPM. It was more like 575 RPM.The video editor that I used was WeVideo. If you download this video and play it with VLC media player you can use the E key to step one frame at a time through the video. The space bar resumes the video.
Robot Arm Development, September 1, 2021 Steve Amorosi 2021-09-02 | Demonstration of a method of controlling a robot arm using a smaller robot arm. This is intended to be a low cost hobby project, using 3D printed parts, servos and low cost electronics.A new SACC Make 2 Robot Arm video is here: youtu.be/XOjnHh01ljY
Halloween Robot 2020 Steve Amorosi 2020-11-01 | Here is the Halloween robot in action on October 31, 2020. The kids liked it. Here is a link to a video of the Halloween robot being tested youtu.be/pEvTePjw7lsNew robot arm video on September 1, 2021: youtu.be/4h_SjuueS3E
Halloween Robot Steve Amorosi 2020-10-22 | A candy delivery method for COVID-19 times.Here is a link to the Halloween robot in action on October 31, 2020. youtu.be/GPvt5-lW4bA The kids liked it. Here is another video of the arm in action.youtu.be/YoCAQo0ANR8An earlier version of the arm design is on Thingiverse at: thingiverse.com/thing:4376591New robot arm video on September 1, 2021: youtu.be/4h_SjuueS3E
Servo Actuated robot arm with Compliant Claw (SACC), Make 2 Steve Amorosi 2020-08-19 | I’ve improved the SACC-26 robot arm and tank bot (youtu.be/y4-tHTKzudc) with many changes. This video shows off some of the capabilities and explains a bit of how the SACC MK2 works. The electronics used are from FIRST Tech Challenge (FTC) and programming was done in FTC Blocks.The arms, base, claw, pulleys are 3d printed. An earlier version of the arm design is on Thingiverse at: thingiverse.com/thing:4376591 I designed it in OpenSCAD and the CAD included. OpenSCAD is a programmers CAD so everything can be changed.New robot arm video on September 1, 2021: youtu.be/4h_SjuueS3E
DNA lei or garland Steve Amorosi 2020-07-18 | This is a video of how I created a 3d printable lei or garland that looks like a strand of DNA. You can download the print files and OpenSCAD model at Thingiverse:thingiverse.com/thing:4542409
FTC Skystone WA State Semi 2-1 and 2-3 Steve Amorosi 2020-05-30 | Jan. 26, 2020, FTC Skystone Washington State Championship, Semifinals 2-1 and 2-3. Blue alliance teams 9915, 11104 and 7462vs. Red alliance 14179, 12611 and 3491Blue wins!
Meet the SACC-26 Robot Arm Steve Amorosi 2020-05-25 | A new SACC Make 2 Robot Arm video is here: youtu.be/XOjnHh01ljYMeet the SACC-26 (Servo Arm with Compliant Claw and 26 inch reach). With 9 inch arms this robot has a horizontal reach of 21 inches and a vertical reach of 26 inches. This outstanding reach is enabled by a low-cost GT2-6mm belt system. With readily available 25 kg-cm (348 oz-in) rated servo motors it can manipulate 10 oz (¼ kg) objects. This video is intended as a high school robotics level teaching tool to describe how to design and analyze a robot arm.The design is at: thingiverse.com/thing:4376591New robot arm video on September 1, 2021: youtu.be/4h_SjuueS3E
SACC-26 Robot Arm Assembly Video Steve Amorosi 2020-05-25 | Make the SACC-26 (Servo Arm with Compliant Claw and 26 inch reach). With 9 inch arms this robot has a horizontal reach of 21 inches and a vertical reach of 26 inches. This outstanding reach is enabled by a low-cost GT2-6mm belt system. With readily available 25 kg-cm (348 oz-in) rated servo motors it can manipulate 10 oz (¼ kg) objects. This video is intended as a high school robotics level teaching tool to describe how to design and analyze a robot arm.The design is at: thingiverse.com/thing:4376591A new SACC Make 2 Robot Arm video is here: youtu.be/XOjnHh01ljYNew robot arm video on September 1, 2021: youtu.be/4h_SjuueS3E
FTC Skystone Washington State Tesla Interleague Semifinal 2 match 3 (tiebreaker) Steve Amorosi 2020-01-12 | Score: Red 82, Blue 76. Red team was 3805 (Atomic Robotics) and 7462 (Not to Scale). Atomic's autonomous routine didn't work but the red team had a double cap stone in the end game.
2020 Washington FTC Skystone Tesla Interleague Qualification Match 30, 136 points! Steve Amorosi 2020-01-12 | Highest score match of the Washington State Skystone Tesla Inteleague. Qualification Match 30. Score: Red 136 vs. Blue 49. Red teams 14179 Sushi Squad and 6427 Wright Angle
FTC Washington Skystone Tesla Interleague Qualification match 2 Steve Amorosi 2020-01-12 | Skystone FIRST Tech Challenge FTC Washington State Tesla Interleage Qualification Match 2. Red alliance 7462 (Not to Scale) & 4213 (Ctrl-Alt-Defeat) vs. Blue 6427 (Wright Angle) & 15070 (Master Blasters Lords of Disasters). Score: Red 79, Blue 58
Skystone Intake 7462 Dec 18 2019 Steve Amorosi 2019-12-19 | This is a video of the stone intake system for our FTC Skystone robot, shot from a Go-pro mounted on the robot.
Sumo Robot Matches, March 9 2019 Steve Amorosi 2019-03-18 | The robots in these matches are autonomous.
FTC 7462 Rover Ruckus League 1 Steve Amorosi 2018-11-04 | Clips from Team 7462 (Not to Scale) competing at November 3, 2018 FTC Rover Ruckus League Match 1
Storable Tube FTC Prototype, April 2017 Steve Amorosi 2018-06-13 | STEM = storable tubular extendible member.
FTC 7462 Relic Recovery Robots 2018 Steve Amorosi 2018-04-08 | FIRST Tech Challenge team FTC 7462 getting their 2018 Relic Recovery robots ready for the post season outreach activities.
FTC 7462 at Washington State Championship 2018 (2 OF 2) Steve Amorosi 2018-02-14 | Team 7462, Not to Scale, from Ingraham High School at the 2018 FTC Relic Recovery Washington State Championship on Feb. 11, 2018
FTC 7462 at Washington State Championship 2018 (1 OF 2) Steve Amorosi 2018-02-14 | Team 7462, Not to Scale, from Ingraham High School at the 2018 FTC Relic Recovery Washington State Championship on Feb. 11, 2018
Calvin up the utility pole Steve Amorosi 2017-12-23 | Rescuing our cat that decided to climb the utility pole.
FTC 7462 at Pasteur Inter League December 2017 Steve Amorosi 2017-12-23 | FTC Team 7462 "not to scale" from Ingraham High School, Seattle, competing at the Pasteur Interleague in Washington on December 16, 2017
2017 FTC Velocity Vortex WA State Finals Steve Amorosi 2017-04-10 | Washington State FTC Velocity Vortex Final Matches, Feb. 4, 2017
FTC 7462 Velocity Vortex Tesla League Steve Amorosi 2017-03-27 | FIRST Technical Challenge (FTC) Team 7462, Not to Scale, from Ingraham High School, Seattle, WA, competing at the Velocity Vortex Tesla Interleague Championship in January 2017.
2016 D1 Womens Ultimate NW Final Whitman Steve Amorosi 2016-05-04 | Whitman Sweets, Woman's Ultimate team playing in the final against U of O, at the NW Regional Championship
FRC 4030 Ingraham Jan 31 2016 Steve Amorosi 2016-03-07 | FRC Team 4030, nullpointerexception, robot at the end of Stronghold week 3 build season.
FRC 4030 STRONGHOLD MAR 5 Steve Amorosi 2016-03-06 | FRC Team 4030, Ingraham Robotics, practicing STRONGHOLD on March 5, 2016. The first competition is next weekend!
FRC 4030 Stronghold Feb 6 2016 Steve Amorosi 2016-02-15 | FRC team 4030, NullPointerException, Ingraham HS, testing the STRONGHOLD robot, Feb 6, 2016.
FTC 7462 WA State Campionship 2016 Steve Amorosi 2016-02-02 | FTC Team 7462 end.of.line, Ingraham High School, at the 2016 RES-Q Washington State Championship.
FRC4030 Stronghold Jan24 2015 Steve Amorosi 2016-02-02 | Ingraham Robotics FRC Team 4030, testing prototypes at the end of week two of Stronghold season.
Ingraham Robotics Jan 16 2016 Steve Amorosi 2016-01-18 | Ingraham FTC Team 7462 at Pasteur Interleague Event, Sat Jan 16, 2016, and a FRC Team 4030 with the prototype robot
FTC 7462 RES Q Babbage League1 Nov 21 2015 Steve Amorosi 2015-11-22 | Team 7462, end.of.line, from Ingraham HS, competing at their first FTC RES-Q League match. The team used cardboard to make a shovel for the front of the robot and was the only team with an autonomous routine.
FTC 7462 at 2 weeks to go Steve Amorosi 2015-11-22 | FTC team 7462, end.of.line, Ingraham HS, Seattle, WA, testing RES-Q robot. Two weeks until the first competition.
Routing 7462 Steve Amorosi 2015-11-18 | Routing the team number in the robot side panel, for FIRST tech challenge (FTC) robot. This is a Shapeoko 2 NC router. The red chip collection tube and the controller case are 3D printed parts.
FRC 4030 Recycle Rush Girls Gen Wa Steve Amorosi 2015-10-18 | FRC Team 4030 at the 2015 Recycle Rush Girls' Generation Event in Washington State
Team4030 Shorewood 2015 RecycleRush Steve Amorosi 2015-03-23 | Team 4030, NullPointerException, Ingraham High School, at the PWN Shorewood District Event, March 22, 2015
Team4030 Recycle Rush Unveiling Steve Amorosi 2015-02-19 | FRC Team 4030, NullPointerException, Ingraham High School, Recycle Rush Robot on the final days of the build season. The students designed and built Swerve Drive, from scratch, in 6 weeks--amazing!
Turkey Heat Capacity Steve Amorosi 2014-12-18 | How to calculate the Heat Capacity of a turkey, by Livia.
Team 7462 Cascade Effect League Match 2 Steve Amorosi 2014-12-16 | Ingraham Robotics, FTC Team 7462, End of Line, Competing at their second Cascade Effect, Babbage League Match, at Kings High School. They set the match high score of 554 points.
FTC 7462 Cascade Effect Babbage League 1 Steve Amorosi 2014-11-25 | Ingraham Robotics Team 7462, End of Line, at the FTC Cascade Effect, Babbage League Event 1, in Shoreline (Seattle), WA
FTC 7462 Cascade Effect video 5 Steve Amorosi 2014-11-17 | Ingraham Robotics, Team 7462, building and driving the robot one week before their first FTC Cascade Effect competition.