Uploaded May 2018 | Updated September 2026, 3 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Tue PM Pod D.4
Authors: Wang, Tao; Li, Yue; Li, Yuanjie; zhang, jinhua; Hong, Jun; Wang, Michael Yu
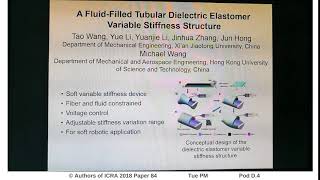
Title: A Fluid-Filled Tubular Dielectric Elastomer Variable Stiffness Structure Inspired by the Hydrostatic Skeleton Principle
Abstract:
This work presents a novel variable stiffness structure consisting of a fiber-constrained dielectric elastomer tube filled with insulating oil. The tensile stiffness of the structure can be adjusted by voltages and its initial value can be customized according to the initial pre-stretch of the material. The structure has a dimension of ~30 mm diameter × 50 mm length. A mathematical analysis is established to predict the initial tensile stiffness of the structure. The changes of the tensile stiffness of the structure under voltages are verified experimentally. The results show a decrease of the tensile stiffness of the device by 25% at 4 kV and the decrement is also related to the elongation of the structure. With different pre-stretches and dimensions of the dielectric elastomer, one can obtain devices with different variation ranges of tensile stiffness.
ICRA 2018 Spotlight Video
Interactive Session Tue PM Pod D.4
Authors: Wang, Tao; Li, Yue; Li, Yuanjie; zhang, jinhua; Hong, Jun; Wang, Michael Yu
Title: A Fluid-Filled Tubular Dielectric Elastomer Variable Stiffness Structure Inspired by the Hydrostatic Skeleton Principle
Abstract:
This work presents a novel variable stiffness structure consisting of a fiber-constrained dielectric elastomer tube filled with insulating oil. The tensile stiffness of the structure can be adjusted by voltages and its initial value can be customized according to the initial pre-stretch of the material. The structure has a dimension of ~30 mm diameter × 50 mm length. A mathematical analysis is established to predict the initial tensile stiffness of the structure. The changes of the tensile stiffness of the structure under voltages are verified experimentally. The results show a decrease of the tensile stiffness of the device by 25% at 4 kV and the decrement is also related to the elongation of the structure. With different pre-stretches and dimensions of the dielectric elastomer, one can obtain devices with different variation ranges of tensile stiffness.